


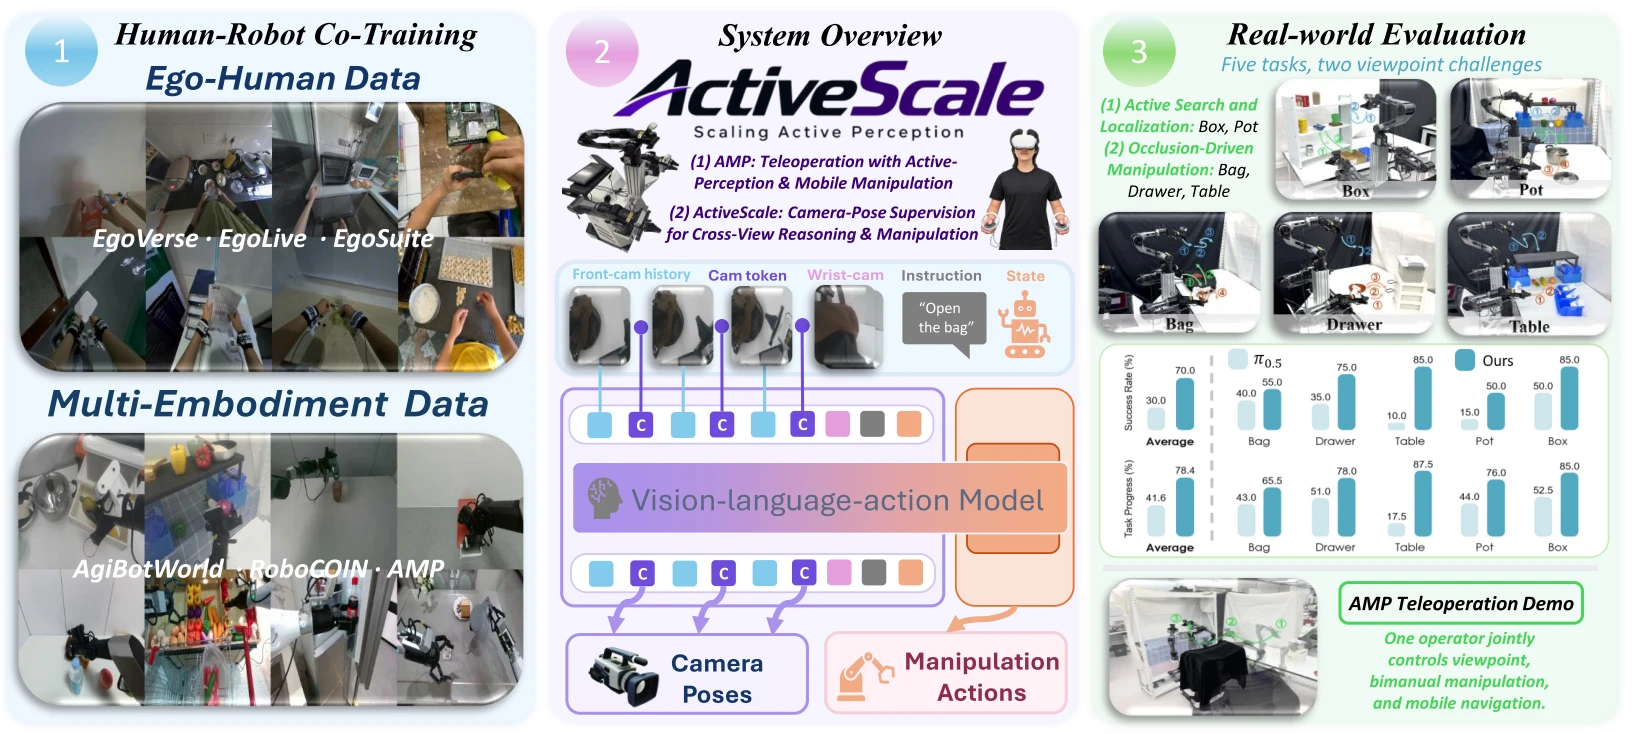
ActiveScale presents a scalable way to study active perception for robot manipulation across model, data, and hardware.
It equips a vision-language-action model with temporal camera observations and camera-pose prediction,
and introduces the Active-perception Mobile-manipulation Platform (AMP) for coordinated viewpoint and manipulation control.
| Checkpoint | Description |
|---|---|
midtraining | Mid-training checkpoint |
bag | Bag task checkpoint |
drawer | Drawer task checkpoint |
pot | Pot task checkpoint |
box | Box task checkpoint |
under | Under-table task checkpoint |
Code and usage: github.com/ShuaiZhou302/ActiveScale