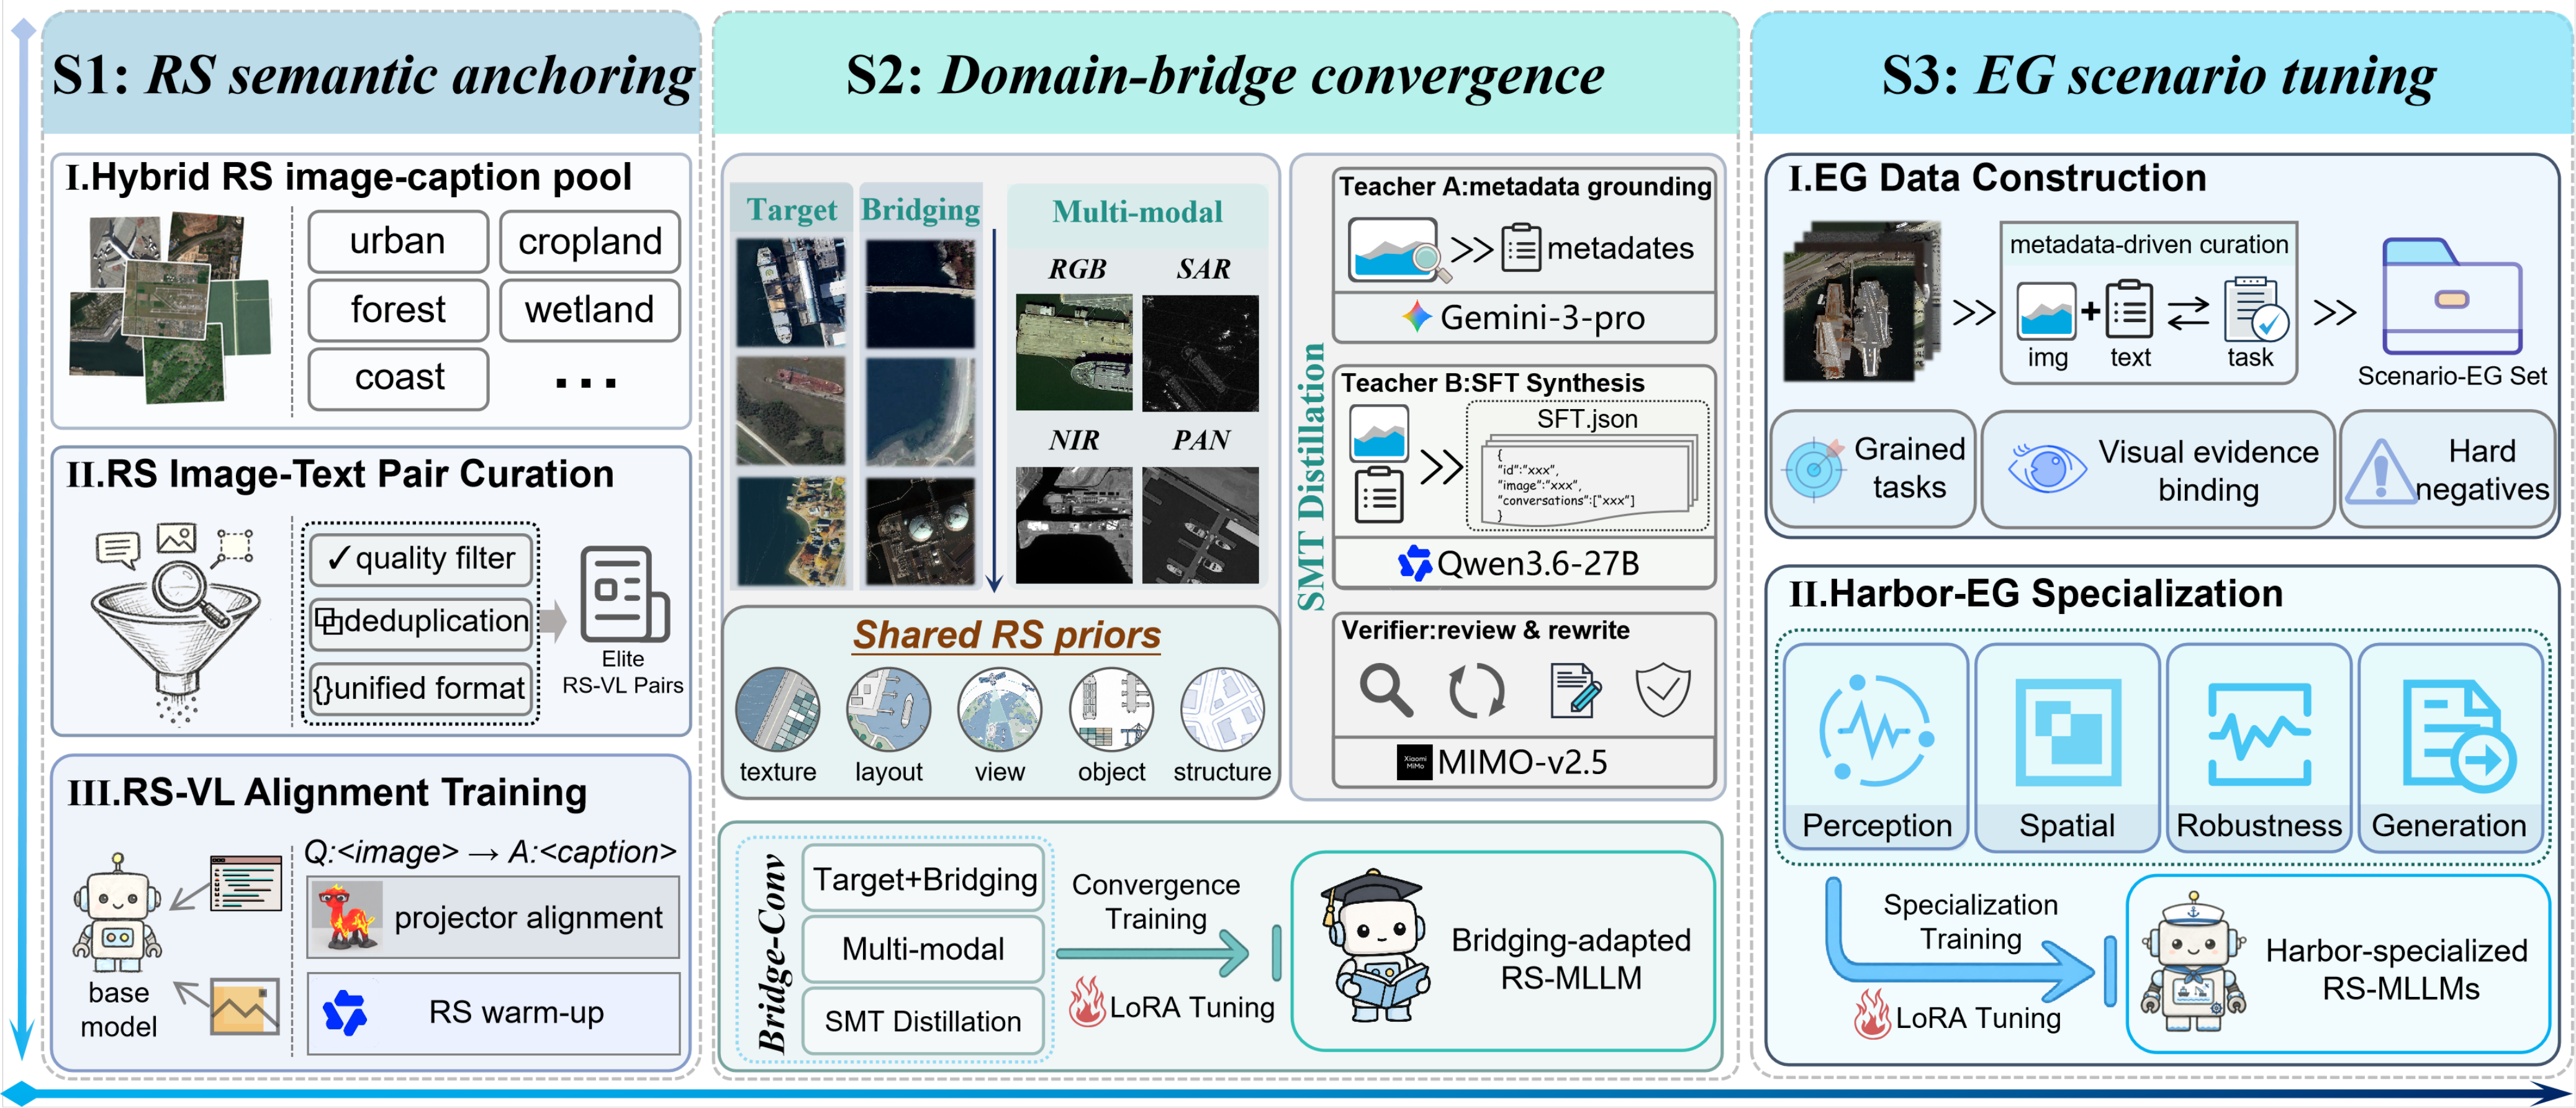
We’re exploring a simple idea: **before asking a model to become a harbor specialist, help it build the skills that the job needs.** That’s what Filling Before Advancing, or **FBA**, is about.
We study this with **LLaVA-v1.5** and **Qwen3-VL**, using harbor imagery from **RGB, SAR, PAN, and NIR** sensors.
> **A small update:** we’ve put the project page and examples online first. Checkpoints and inference instructions will follow after paper acceptance.
>
> 我们先把项目介绍和样例放在这里。论文录用后,会陆续补上模型权重和使用方法,欢迎回来看看。
## Pages and files
**Updated 2026-10-04.** The website and HF preview pages are online; resource files are a separate release. Both HF repositories currently contain only README.md and .gitattributes.
| Artifact | File availability | Public version |
| --- | --- | --- |
| Training & evaluation code | Not released · package in preparation | — |
| FBA / LLaVA-v1.5-7B weights | Not released · checkpoint package in preparation | — |
| FBA / Qwen3-VL-8B weights | Not released · checkpoint package in preparation | — |
| CPRS full dataset | Not released · source permissions under review | — |
| HarborEval evaluation package | Not released · public evaluation package in preparation | — |
**— means no public resource version yet.** Base-model names are not FBA release versions. Releases are planned progressively after paper acceptance. Public examples remain illustrative; HarborEval reference answers and scoring notes are currently private.
[Shared checklist](https://github.com/Z0ngL1ng/filling-before-advancing/blob/main/RELEASE_STATUS.md) · [License scope](https://github.com/Z0ngL1ng/filling-before-advancing/blob/main/LICENSE_SCOPE.md)
## How it works
The route has three steps:
1. **RS-Anchor** — learn to read overhead imagery and connect it with language.
2. **Bridge-Conv** — learn from related coastal scenes across different sensors.
3. **Scenario-EG** — answer harbor questions, locate objects with a grid, and write reports using visible evidence.