


Complete EgoRayFormer model card and include DINOv3 license
Browse files- LICENSE_DINOv3.md +66 -0
- README.md +213 -1
LICENSE_DINOv3.md
ADDED
|
@@ -0,0 +1,66 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
# DINOv3 License
|
| 2 |
+
|
| 3 |
+
*Last Updated: August 19, 2025*
|
| 4 |
+
|
| 5 |
+
**“Agreement”** means the terms and conditions for use, reproduction, distribution and modification of the DINO Materials set forth herein.
|
| 6 |
+
|
| 7 |
+
**“DINO Materials”** means, collectively, Documentation and the models, software and algorithms, including machine-learning model code, trained model weights, inference-enabling code, training-enabling code, fine-tuning enabling code, and other elements of the foregoing distributed by Meta and made available under this Agreement.
|
| 8 |
+
|
| 9 |
+
**“Documentation”** means the specifications, manuals and documentation accompanying
|
| 10 |
+
DINO Materials distributed by Meta.
|
| 11 |
+
|
| 12 |
+
**“Licensee”** or **“you”** means you, or your employer or any other person or entity (if you are entering into this Agreement on such person or entity’s behalf), of the age required under applicable laws, rules or regulations to provide legal consent and that has legal authority to bind your employer or such other person or entity if you are entering in this Agreement on their behalf.
|
| 13 |
+
|
| 14 |
+
**“Meta”** or **“we”** means Meta Platforms Ireland Limited (if you are located in or, if you are an entity, your principal place of business is in the EEA or Switzerland) or Meta Platforms, Inc. (if you are located outside of the EEA or Switzerland).
|
| 15 |
+
|
| 16 |
+
**“Sanctions”** means any economic or trade sanctions or restrictions administered or enforced by the United States (including the Office of Foreign Assets Control of the U.S. Department of the Treasury (“OFAC”), the U.S. Department of State and the U.S. Department of Commerce), the United Nations, the European Union, or the United Kingdom.
|
| 17 |
+
|
| 18 |
+
**“Trade Controls”** means any of the following: Sanctions and applicable export and import controls.
|
| 19 |
+
|
| 20 |
+
By clicking “I Accept” below or by using or distributing any portion or element of the DINO Materials, you agree to be bound by this Agreement.
|
| 21 |
+
|
| 22 |
+
## 1. License Rights and Redistribution.
|
| 23 |
+
|
| 24 |
+
a. <ins>Grant of Rights</ins>. You are granted a non-exclusive, worldwide, non-transferable and royalty-free limited license under Meta’s intellectual property or other rights owned by Meta embodied in the DINO Materials to use, reproduce, distribute, copy, create derivative works of, and make modifications to the DINO Materials.
|
| 25 |
+
|
| 26 |
+
b. <ins>Redistribution and Use</ins>.
|
| 27 |
+
|
| 28 |
+
i. Distribution of DINO Materials, and any derivative works thereof, are subject to the terms of this Agreement. If you distribute or make the DINO Materials, or any derivative works thereof, available to a third party, you may only do so under the terms of this Agreement and you shall provide a copy of this Agreement with any such DINO Materials.
|
| 29 |
+
|
| 30 |
+
ii. If you submit for publication the results of research you perform on, using, or otherwise in connection with DINO Materials, you must acknowledge the use of DINO Materials in your publication.
|
| 31 |
+
|
| 32 |
+
iii. Your use of the DINO Materials must comply with applicable laws and regulations, including Trade Control Laws and applicable privacy and data protection laws.
|
| 33 |
+
|
| 34 |
+
iv. Your use of the DINO Materials will not involve or encourage others to reverse engineer, decompile or discover the underlying components of the DINO Materials.
|
| 35 |
+
|
| 36 |
+
v. You are not the target of Trade Controls and your use of DINO Materials must comply with Trade Controls. You agree not to use, or permit others to use, DINO Materials for any activities subject to the International Traffic in Arms Regulations (ITAR) or end uses prohibited by Trade Controls, including those related to military or warfare purposes, nuclear industries or applications, espionage, or the development or use of guns or illegal weapons.
|
| 37 |
+
|
| 38 |
+
## 2. User Support.
|
| 39 |
+
|
| 40 |
+
Your use of the DINO Materials is done at your own discretion; Meta does not process any information nor provide any service in relation to such use. Meta is under no obligation to provide any support services for the DINO Materials. Any support provided is “as is”, “with all faults”, and without warranty of any kind.
|
| 41 |
+
|
| 42 |
+
## 3. Disclaimer of Warranty.
|
| 43 |
+
|
| 44 |
+
UNLESS REQUIRED BY APPLICABLE LAW, THE DINO MATERIALS AND ANY OUTPUT AND RESULTS THEREFROM ARE PROVIDED ON AN “AS IS” BASIS, WITHOUT WARRANTIES OF ANY KIND, AND META DISCLAIMS ALL WARRANTIES OF ANY KIND, BOTH EXPRESS AND IMPLIED, INCLUDING, WITHOUT LIMITATION, ANY WARRANTIES OF TITLE, NON-INFRINGEMENT, MERCHANTABILITY, OR FITNESS FOR A PARTICULAR PURPOSE. YOU ARE SOLELY RESPONSIBLE FOR DETERMINING THE APPROPRIATENESS OF USING OR REDISTRIBUTING THE DINO MATERIALS AND ASSUME ANY RISKS ASSOCIATED WITH YOUR USE OF THE DINO MATERIALS AND ANY OUTPUT AND RESULTS.
|
| 45 |
+
|
| 46 |
+
## 4. Limitation of Liability.
|
| 47 |
+
|
| 48 |
+
IN NO EVENT WILL META OR ITS AFFILIATES BE LIABLE UNDER ANY THEORY OF LIABILITY, WHETHER IN CONTRACT, TORT, NEGLIGENCE, PRODUCTS LIABILITY, OR OTHERWISE, ARISING OUT OF THIS AGREEMENT, FOR ANY LOST PROFITS OR ANY DIRECT OR INDIRECT, SPECIAL, CONSEQUENTIAL, INCIDENTAL, EXEMPLARY OR PUNITIVE DAMAGES, EVEN IF META OR ITS AFFILIATES HAVE BEEN ADVISED OF THE POSSIBILITY OF ANY OF THE FOREGOING.
|
| 49 |
+
|
| 50 |
+
## 5. Intellectual Property.
|
| 51 |
+
|
| 52 |
+
a. Subject to Meta’s ownership of DINO Materials and derivatives made by or for Meta, with respect to any derivative works and modifications of the DINO Materials that are made by you, as between you and Meta, you are and will be the owner of such derivative works and modifications.
|
| 53 |
+
|
| 54 |
+
b. If you institute litigation or other proceedings against Meta or any entity (including a cross-claim or counterclaim in a lawsuit) alleging that the DINO Materials, outputs or results, or any portion of any of the foregoing, constitutes infringement of intellectual property or other rights owned or licensable by you, then any licenses granted to you under this Agreement shall terminate as of the date such litigation or claim is filed or instituted. You will indemnify and hold harmless Meta from and against any claim by any third party arising out of or related to your use or distribution of the DINO Materials.
|
| 55 |
+
|
| 56 |
+
## 6. Term and Termination.
|
| 57 |
+
|
| 58 |
+
The term of this Agreement will commence upon your acceptance of this Agreement or access to the DINO Materials and will continue in full force and effect until terminated in accordance with the terms and conditions herein. Meta may terminate this Agreement if you are in breach of any term or condition of this Agreement. Upon termination of this Agreement, you shall delete and cease use of the DINO Materials. Sections 3, 4 and 7 shall survive the termination of this Agreement.
|
| 59 |
+
|
| 60 |
+
## 7. Governing Law and Jurisdiction.
|
| 61 |
+
|
| 62 |
+
This Agreement will be governed and construed under the laws of the State of California without regard to choice of law principles, and the UN Convention on Contracts for the International Sale of Goods does not apply to this Agreement. The courts of California shall have exclusive jurisdiction of any dispute arising out of this Agreement.
|
| 63 |
+
|
| 64 |
+
## 8. Modifications and Amendments.
|
| 65 |
+
|
| 66 |
+
Meta may modify this Agreement from time to time; provided that they are similar in spirit to the current version of the Agreement, but may differ in detail to address new problems or concerns. All such changes will be effective immediately. Your continued use of the DINO Materials after any modification to this Agreement constitutes your agreement to such modification. Except as provided in this Agreement, no modification or addition to any provision of this Agreement will be binding unless it is in writing and signed by an authorized representative of both you and Meta.
|
README.md
CHANGED
|
@@ -1,3 +1,215 @@
|
|
| 1 |
---
|
| 2 |
-
license:
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 3 |
---
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
---
|
| 2 |
+
license: other
|
| 3 |
+
license_name: dinov3-license
|
| 4 |
+
license_link: https://huggingface.co/BodenAI/EgoRayFormer/blob/main/LICENSE_DINOv3.md
|
| 5 |
+
library_name: pytorch
|
| 6 |
+
pipeline_tag: keypoint-detection
|
| 7 |
+
base_model: timm/vit_small_plus_patch16_dinov3.lvd1689m
|
| 8 |
+
tags:
|
| 9 |
+
- egocentric
|
| 10 |
+
- 3d-human-pose-estimation
|
| 11 |
+
- human-pose-estimation
|
| 12 |
+
- stereo
|
| 13 |
+
- fisheye
|
| 14 |
+
- pytorch-lightning
|
| 15 |
+
metrics:
|
| 16 |
+
- mpjpe
|
| 17 |
+
- pa-mpjpe
|
| 18 |
+
model-index:
|
| 19 |
+
- name: egorayformer_ue2.ckpt
|
| 20 |
+
results:
|
| 21 |
+
- task:
|
| 22 |
+
type: keypoint-detection
|
| 23 |
+
name: Egocentric 3D human pose estimation
|
| 24 |
+
dataset:
|
| 25 |
+
type: unrealego2
|
| 26 |
+
name: UnrealEgo2
|
| 27 |
+
split: test
|
| 28 |
+
metrics:
|
| 29 |
+
- type: mpjpe
|
| 30 |
+
name: MPJPE (mm)
|
| 31 |
+
value: 17.53
|
| 32 |
+
- type: pa-mpjpe
|
| 33 |
+
name: PA-MPJPE (mm)
|
| 34 |
+
value: 16.8
|
| 35 |
+
- name: egorayformer_rw.ckpt
|
| 36 |
+
results:
|
| 37 |
+
- task:
|
| 38 |
+
type: keypoint-detection
|
| 39 |
+
name: Egocentric 3D human pose estimation
|
| 40 |
+
dataset:
|
| 41 |
+
type: unrealego-rw
|
| 42 |
+
name: UnrealEgo-RW
|
| 43 |
+
split: test
|
| 44 |
+
metrics:
|
| 45 |
+
- type: mpjpe
|
| 46 |
+
name: MPJPE (mm)
|
| 47 |
+
value: 49.34
|
| 48 |
+
- type: pa-mpjpe
|
| 49 |
+
name: PA-MPJPE (mm)
|
| 50 |
+
value: 40.59
|
| 51 |
+
- name: egorayformer_ue2_to_rw.ckpt
|
| 52 |
+
results:
|
| 53 |
+
- task:
|
| 54 |
+
type: keypoint-detection
|
| 55 |
+
name: Egocentric 3D human pose estimation
|
| 56 |
+
dataset:
|
| 57 |
+
type: unrealego-rw
|
| 58 |
+
name: UnrealEgo-RW
|
| 59 |
+
split: test
|
| 60 |
+
metrics:
|
| 61 |
+
- type: mpjpe
|
| 62 |
+
name: MPJPE (mm)
|
| 63 |
+
value: 47.68
|
| 64 |
+
- type: pa-mpjpe
|
| 65 |
+
name: PA-MPJPE (mm)
|
| 66 |
+
value: 37.73
|
| 67 |
---
|
| 68 |
+
|
| 69 |
+
<p align="center">
|
| 70 |
+
<img src="https://raw.githubusercontent.com/BodenAI/EgoRayFormer/main/docs/logo/en_logo.png" alt="BODENAI" width="220">
|
| 71 |
+
</p>
|
| 72 |
+
|
| 73 |
+
<h1 align="center">EgoRayFormer</h1>
|
| 74 |
+
|
| 75 |
+
<p align="center"><b>EgoRayFormer: Ray-Space Stereo Refinement for Egocentric 3D Human Pose Estimation</b></p>
|
| 76 |
+
|
| 77 |
+
<p align="center">
|
| 78 |
+
<a href="https://arxiv.org/abs/2610.26641">Paper</a> ·
|
| 79 |
+
<a href="https://github.com/BodenAI/EgoRayFormer">Code</a>
|
| 80 |
+
</p>
|
| 81 |
+
|
| 82 |
+
<p align="center">Haozhe Wang, Songyuan Wu, Jihai Xu, Jie Zhao · Boden AI</p>
|
| 83 |
+
|
| 84 |
+
<p align="center"><b>Built with DINOv3</b></p>
|
| 85 |
+
|
| 86 |
+
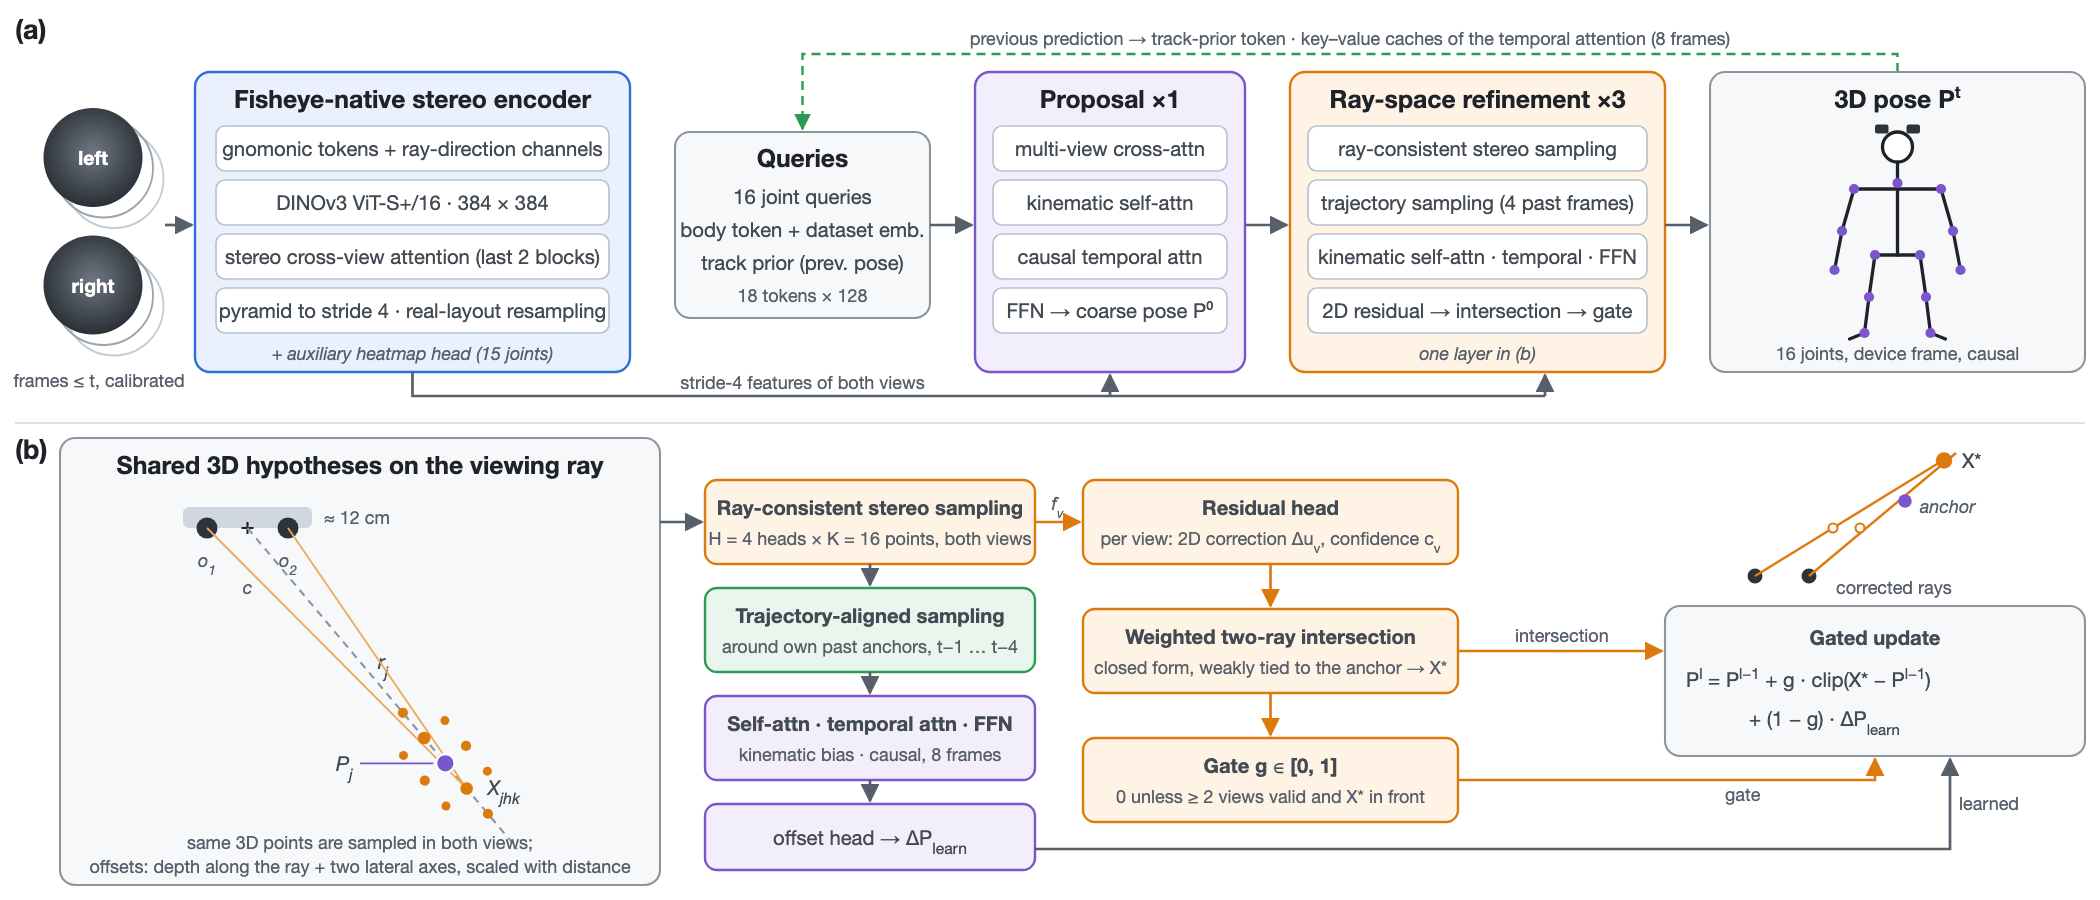
This repository holds the checkpoints of [EgoRayFormer](https://arxiv.org/abs/2610.26641), a causal 3D human pose
|
| 87 |
+
estimator for head-mounted stereo fisheye cameras. For each joint, the decoder projects shared 3D hypotheses along and
|
| 88 |
+
around its viewing ray into both images. A geometric branch then corrects the projected joint locations and intersects
|
| 89 |
+
the resulting rays, and a learned gate blends this geometric estimate with a learned pose update. Code, training and
|
| 90 |
+
evaluation: [github.com/BodenAI/EgoRayFormer](https://github.com/BodenAI/EgoRayFormer).
|
| 91 |
+
|
| 92 |
+
|
| 93 |
+
|
| 94 |
+
## Checkpoints
|
| 95 |
+
|
| 96 |
+
Three models of Table 1 of the paper, all with a DINOv3 ViT-S+/16 encoder at 384 × 384 (35.1 M parameters in total). Each file
|
| 97 |
+
contains the EMA weights used for evaluation (approximately 134 MiB per checkpoint).
|
| 98 |
+
|
| 99 |
+
| File | Training data | Test set | Config |
|
| 100 |
+
|---|---|---|---|
|
| 101 |
+
| [`egorayformer_ue2.ckpt`](https://huggingface.co/BodenAI/EgoRayFormer/resolve/main/egorayformer_ue2.ckpt) | UnrealEgo2 | UnrealEgo2 | [`configs/egorayformer_ue2.yaml`](https://github.com/BodenAI/EgoRayFormer/blob/main/configs/egorayformer_ue2.yaml) |
|
| 102 |
+
| [`egorayformer_rw.ckpt`](https://huggingface.co/BodenAI/EgoRayFormer/resolve/main/egorayformer_rw.ckpt) | UnrealEgo-RW | UnrealEgo-RW | [`configs/egorayformer_rw.yaml`](https://github.com/BodenAI/EgoRayFormer/blob/main/configs/egorayformer_rw.yaml) |
|
| 103 |
+
| [`egorayformer_ue2_to_rw.ckpt`](https://huggingface.co/BodenAI/EgoRayFormer/resolve/main/egorayformer_ue2_to_rw.ckpt) | UnrealEgo2, then UnrealEgo-RW | UnrealEgo-RW | [`configs/egorayformer_ue2_to_rw.yaml`](https://github.com/BodenAI/EgoRayFormer/blob/main/configs/egorayformer_ue2_to_rw.yaml) |
|
| 104 |
+
|
| 105 |
+
SHA-256:
|
| 106 |
+
|
| 107 |
+
```
|
| 108 |
+
f4a0028421d3b9a1d8bb45fe3d336e072d8036a59afc4841fb03c5d7ce9c5100 egorayformer_ue2.ckpt
|
| 109 |
+
5b4612438b6204bab198f9e9d1cc7e696cd919052bc48c5cd084676e932f4c08 egorayformer_rw.ckpt
|
| 110 |
+
dfeb9c2867e14f4df97cda35f8fbffa37ba34f003e5a3b4133753a73ce12856e egorayformer_ue2_to_rw.ckpt
|
| 111 |
+
```
|
| 112 |
+
|
| 113 |
+
## Results
|
| 114 |
+
|
| 115 |
+
Device-relative protocol on the official test splits, mm. Every sequence is processed as one causal stream in FP32.
|
| 116 |
+
The released files are the seed-42 models; the paper reports the mean ± s.d. over seeds 42, 1 and 2.
|
| 117 |
+
|
| 118 |
+
| Model | Test set | MPJPE (this checkpoint) | PA-MPJPE (this checkpoint) | MPJPE (paper, 3 seeds) | PA-MPJPE (paper, 3 seeds) |
|
| 119 |
+
|---|---|---|---|---|---|
|
| 120 |
+
| `egorayformer_ue2` | UnrealEgo2 | 17.53 | 16.80 | 17.64 ± 0.12 | 16.86 ± 0.08 |
|
| 121 |
+
| `egorayformer_rw` | UnrealEgo-RW | 49.34 | 40.59 | 49.55 ± 0.40 | 40.59 ± 0.30 |
|
| 122 |
+
| `egorayformer_ue2_to_rw` | UnrealEgo-RW | 47.68 | 37.73 | 47.57 ± 0.34 | 37.21 ± 0.46 |
|
| 123 |
+
|
| 124 |
+
See the paper for the comparison with other methods.
|
| 125 |
+
|
| 126 |
+
## Usage
|
| 127 |
+
|
| 128 |
+
The checkpoints are used with the code repository. Install it, prepare the UnrealEgo2 / UnrealEgo-RW records with the
|
| 129 |
+
scripts of the repository (see its README), then download a checkpoint and evaluate it:
|
| 130 |
+
|
| 131 |
+
```bash
|
| 132 |
+
git clone https://github.com/BodenAI/EgoRayFormer.git && cd EgoRayFormer
|
| 133 |
+
pip install torch==2.4.0 torchvision==0.19.0 --index-url https://download.pytorch.org/whl/cu121
|
| 134 |
+
pip install -e .
|
| 135 |
+
|
| 136 |
+
mkdir -p checkpoints
|
| 137 |
+
for m in egorayformer_ue2 egorayformer_rw egorayformer_ue2_to_rw; do
|
| 138 |
+
wget -P checkpoints https://huggingface.co/BodenAI/EgoRayFormer/resolve/main/$m.ckpt
|
| 139 |
+
done
|
| 140 |
+
|
| 141 |
+
python run.py validate --config configs/egorayformer_rw.yaml --config configs/eval.yaml \
|
| 142 |
+
--model.model.encoder.pretrained false --data.root /data/unrealego/processed \
|
| 143 |
+
--ckpt_path checkpoints/egorayformer_rw.ckpt
|
| 144 |
+
```
|
| 145 |
+
|
| 146 |
+
Use `egorayformer_ue2` or `egorayformer_ue2_to_rw` for the other two models. For the test split, run
|
| 147 |
+
`EGORAYFORMER_ALLOW_TEST=1 python run.py test` with the same arguments. `--model.model.encoder.pretrained false` skips
|
| 148 |
+
the download of the DINOv3 weights, which come from the checkpoint.
|
| 149 |
+
|
| 150 |
+
**Input.** Stereo fisheye video from a head-mounted rig: the left and right images of each frame (resized to
|
| 151 |
+
384 × 384) and the calibration of the rig (fisheye camera models and camera-from-device extrinsics). The model projects
|
| 152 |
+
3D hypotheses into both images, so the calibration is part of the input. It processes frames causally and keeps a
|
| 153 |
+
streaming state (key–value caches, trajectory history, previous pose).
|
| 154 |
+
|
| 155 |
+
**Output.** The 3D positions of 16 joints (UnrealEgo skeleton: head, neck, upper arms, lower arms, hands, thighs,
|
| 156 |
+
calves, feet, balls of the feet) relative to the device, for every frame.
|
| 157 |
+
|
| 158 |
+
## Training
|
| 159 |
+
|
| 160 |
+
Each model is trained in two stages on one NVIDIA H200 GPU:
|
| 161 |
+
|
| 162 |
+
1. 2D heatmap pre-training of the encoder at 256 × 256, starting from the DINOv3 ViT-S+/16 weights
|
| 163 |
+
(`timm/vit_small_plus_patch16_dinov3.lvd1689m`);
|
| 164 |
+
2. end-to-end training on clips of 8 consecutive frames at 384 × 384, batch size 16, AdamW, bf16 mixed precision:
|
| 165 |
+
12 epochs on UnrealEgo-RW, 3 epochs on UnrealEgo2. The UnrealEgo2 → UnrealEgo-RW model starts from the weights of the
|
| 166 |
+
UnrealEgo2 model and is trained for 12 epochs on UnrealEgo-RW.
|
| 167 |
+
|
| 168 |
+
The checkpoint with the lowest validation MPJPE is selected. The commands are in the README of the code repository.
|
| 169 |
+
|
| 170 |
+
**Data.** [UnrealEgo2 and UnrealEgo-RW](https://unrealego.mpi-inf.mpg.de/) (Akada et al., CVPR 2024), official splits.
|
| 171 |
+
UnrealEgo2 is rendered with a synthetic stereo fisheye rig; UnrealEgo-RW was captured with a physical head-mounted rig.
|
| 172 |
+
For UnrealEgo-RW, the camera-from-device transform of every capture session is fitted to the training annotations only.
|
| 173 |
+
|
| 174 |
+
## Limitations
|
| 175 |
+
|
| 176 |
+
- The models were trained and evaluated on the two rigs of UnrealEgo2 and UnrealEgo-RW only. Other headsets need their
|
| 177 |
+
calibration, and accuracy on other rigs has not been evaluated.
|
| 178 |
+
- Errors increase with the distance of a joint from the cameras; the lower body has the largest errors.
|
| 179 |
+
- One streaming step takes about 43 ms on an NVIDIA H200 (FP32, batch 1, model forward only), so the numbers above do
|
| 180 |
+
not establish real-time operation on other hardware.
|
| 181 |
+
- The models estimate the pose of the person wearing the headset; they are intended for research.
|
| 182 |
+
|
| 183 |
+
## License
|
| 184 |
+
|
| 185 |
+
The checkpoints contain weights derived from DINOv3 and are distributed under the
|
| 186 |
+
[DINOv3 License](LICENSE_DINOv3.md). The code is released under the Apache License 2.0 in the
|
| 187 |
+
[code repository](https://github.com/BodenAI/EgoRayFormer). UnrealEgo2 and UnrealEgo-RW are distributed by their authors
|
| 188 |
+
under their own terms.
|
| 189 |
+
|
| 190 |
+
## Citation
|
| 191 |
+
|
| 192 |
+
```bibtex
|
| 193 |
+
@article{wang2026egorayformer,
|
| 194 |
+
title = {{EgoRayFormer}: Ray-Space Stereo Refinement for Egocentric {3D} Human Pose Estimation},
|
| 195 |
+
author = {Wang, Haozhe and Wu, Songyuan and Xu, Jihai and Zhao, Jie},
|
| 196 |
+
journal = {arXiv preprint arXiv:2610.26641},
|
| 197 |
+
year = {2026}
|
| 198 |
+
}
|
| 199 |
+
```
|
| 200 |
+
|
| 201 |
+
## Contact Us
|
| 202 |
+
|
| 203 |
+
<p align="center">
|
| 204 |
+
<img src="https://raw.githubusercontent.com/BodenAI/EgoRayFormer/main/docs/logo/code.jpg" alt="WeChat QR code" width="110">
|
| 205 |
+
</p>
|
| 206 |
+
|
| 207 |
+
<p align="center">
|
| 208 |
+
<a href="https://bodenai.com">bodenai.com</a> (中文) ·
|
| 209 |
+
<a href="https://www.boden.ai">boden.ai</a> (English)
|
| 210 |
+
</p>
|
| 211 |
+
|
| 212 |
+
<p align="center">
|
| 213 |
+
<a href="mailto:company@bodenai.com">company@bodenai.com</a> ·
|
| 214 |
+
<a href="mailto:EAI@bodenai.com">EAI@bodenai.com</a>
|
| 215 |
+
</p>
|