


docs: add comprehensive Model Card for MatchFormer (ACCV 2022)
Browse files
README.md
ADDED
|
@@ -0,0 +1,105 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
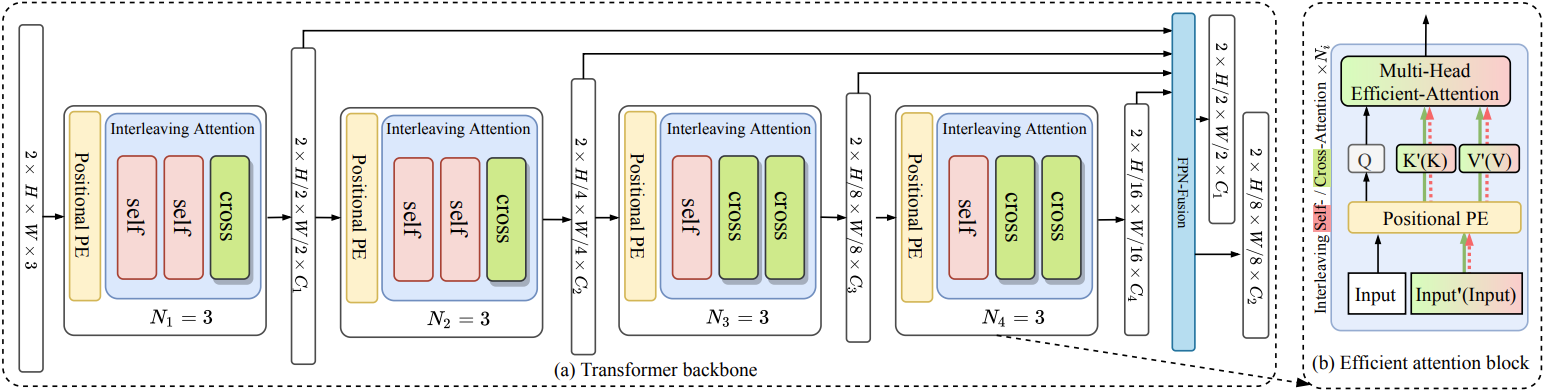
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
---
|
| 2 |
+
pipeline_tag: feature-matching
|
| 3 |
+
library_name: pytorch
|
| 4 |
+
license: apache-2.0
|
| 5 |
+
tags:
|
| 6 |
+
- transformer
|
| 7 |
+
- feature-matching
|
| 8 |
+
- accv-2022
|
| 9 |
+
- vision
|
| 10 |
+
- scannet
|
| 11 |
+
- megadepth
|
| 12 |
+
datasets:
|
| 13 |
+
- scannet
|
| 14 |
+
- megadepth
|
| 15 |
+
---
|
| 16 |
+
|
| 17 |
+
# MatchFormer: Interleaving Attention in Transformers for Feature Matching (ACCV 2022)
|
| 18 |
+
|
| 19 |
+
Official model checkpoints for **MatchFormer: Interleaving Attention in Transformers for Feature Matching** (ACCV 2022 Oral).
|
| 20 |
+
|
| 21 |
+
<div align="center">
|
| 22 |
+
|
| 23 |
+
[](https://arxiv.org/abs/2203.09645)
|
| 24 |
+
[](https://github.com/InSAI-Lab/MatchFormer)
|
| 25 |
+
[](https://huggingface.co/collections/InSAI-Lab)
|
| 26 |
+
|
| 27 |
+
</div>
|
| 28 |
+
|
| 29 |
+
---
|
| 30 |
+
|
| 31 |
+
## 📌 Introduction
|
| 32 |
+
|
| 33 |
+
In this work, we propose a novel hierarchical extract-and-match transformer, termed **MatchFormer**. Inside each stage of the hierarchical encoder, we interleave self-attention for feature extraction and cross-attention for feature matching, enabling an intuitive and powerful **extract-and-match** scheme. MatchFormer establishes robust and accurate dense correspondences across diverse indoor and outdoor challenging scenes.
|
| 34 |
+
|
| 35 |
+
|
| 36 |
+
|
| 37 |
+
---
|
| 38 |
+
|
| 39 |
+
## 📂 Model Zoo & File Structure
|
| 40 |
+
|
| 41 |
+
```text
|
| 42 |
+
InSAI-Lab/MatchFormer
|
| 43 |
+
├── indoor-large-SEA.ckpt # Indoor large model with SEA (Spatial-Entropy Attention) (89.5 MB)
|
| 44 |
+
├── indoor-lite-LA.ckpt # Indoor lightweight model with LA (Linear Attention) (77.4 MB)
|
| 45 |
+
├── outdoor-large-LA.ckpt # Outdoor large model with LA (77.4 MB)
|
| 46 |
+
└── outdoor-lite-SEA.ckpt # Outdoor lightweight model with SEA (103.5 MB)
|
| 47 |
+
```
|
| 48 |
+
|
| 49 |
+
---
|
| 50 |
+
|
| 51 |
+
## 📊 Benchmark Results
|
| 52 |
+
|
| 53 |
+
### 1. Indoor Relative Pose Estimation on ScanNet (AUC)
|
| 54 |
+
|
| 55 |
+
| Model | Backbone | Resolution | AUC @ 5° | AUC @ 10° | AUC @ 20° | Weights |
|
| 56 |
+
| :--- | :--- | :---: | :---: | :---: | :---: | :--- |
|
| 57 |
+
| **MatchFormer-Large** | largesea | (8, 2) | **43.3** | **63.4** | **77.1** | [`indoor-large-SEA.ckpt`](https://huggingface.co/InSAI-Lab/MatchFormer/resolve/main/indoor-large-SEA.ckpt) |
|
| 58 |
+
| **MatchFormer-Lite** | litela | (8, 4) | **38.8** | **59.2** | **74.0** | [`indoor-lite-LA.ckpt`](https://huggingface.co/InSAI-Lab/MatchFormer/resolve/main/indoor-lite-LA.ckpt) |
|
| 59 |
+
|
| 60 |
+
### 2. Outdoor Relative Pose Estimation on MegaDepth (AUC)
|
| 61 |
+
|
| 62 |
+
| Model | Backbone | Resolution | AUC @ 5° | AUC @ 10° | AUC @ 20° | Weights |
|
| 63 |
+
| :--- | :--- | :---: | :---: | :---: | :---: | :--- |
|
| 64 |
+
| **MatchFormer-Large** | largela | (8, 2) | **53.3** | **69.7** | **81.8** | [`outdoor-large-LA.ckpt`](https://huggingface.co/InSAI-Lab/MatchFormer/resolve/main/outdoor-large-LA.ckpt) |
|
| 65 |
+
| **MatchFormer-Lite** | litesea | (8, 4) | **48.2** | **65.1** | **78.4** | [`outdoor-lite-SEA.ckpt`](https://huggingface.co/InSAI-Lab/MatchFormer/resolve/main/outdoor-lite-SEA.ckpt) |
|
| 66 |
+
|
| 67 |
+
---
|
| 68 |
+
|
| 69 |
+
## ⚡ Quick Download Guide
|
| 70 |
+
|
| 71 |
+
### Option 1: Hugging Face CLI
|
| 72 |
+
|
| 73 |
+
```bash
|
| 74 |
+
# Download all MatchFormer weights to model/weights/
|
| 75 |
+
hf download InSAI-Lab/MatchFormer --local-dir model/weights
|
| 76 |
+
|
| 77 |
+
# Or download a specific checkpoint
|
| 78 |
+
hf download InSAI-Lab/MatchFormer indoor-large-SEA.ckpt --local-dir model/weights
|
| 79 |
+
```
|
| 80 |
+
|
| 81 |
+
### Option 2: Python `huggingface_hub`
|
| 82 |
+
|
| 83 |
+
```python
|
| 84 |
+
from huggingface_hub import hf_hub_download
|
| 85 |
+
|
| 86 |
+
# Download indoor large SEA checkpoint
|
| 87 |
+
ckpt_path = hf_hub_download(
|
| 88 |
+
repo_id="InSAI-Lab/MatchFormer",
|
| 89 |
+
filename="indoor-large-SEA.ckpt",
|
| 90 |
+
local_dir="model/weights"
|
| 91 |
+
)
|
| 92 |
+
```
|
| 93 |
+
|
| 94 |
+
---
|
| 95 |
+
|
| 96 |
+
## 📖 Citation
|
| 97 |
+
|
| 98 |
+
```bibtex
|
| 99 |
+
@inproceedings{wang2022matchformer,
|
| 100 |
+
title={MatchFormer: Interleaving Attention in Transformers for Feature Matching},
|
| 101 |
+
author={Wang, Qing and Zhang, Jiaming and Yang, Kailun and Peng, Kunyu and Stiefelhagen, Rainer},
|
| 102 |
+
booktitle={Asian Conference on Computer Vision (ACCV)},
|
| 103 |
+
year={2022}
|
| 104 |
+
}
|
| 105 |
+
```
|