
Datasets:

Update README.md
Browse files
README.md
CHANGED
|
@@ -1,3 +1,72 @@
|
|
| 1 |
---
|
|
|
|
|
|
|
|
|
|
|
|
|
| 2 |
license: cc-by-nc-4.0
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 3 |
---
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
---
|
| 2 |
+
annotations_creators:
|
| 3 |
+
- synthetic
|
| 4 |
+
language:
|
| 5 |
+
- en
|
| 6 |
license: cc-by-nc-4.0
|
| 7 |
+
task_categories:
|
| 8 |
+
- depth-estimation
|
| 9 |
+
- image-to-3d
|
| 10 |
+
tags:
|
| 11 |
+
- forgeoptics
|
| 12 |
+
- 3d-vision
|
| 13 |
+
- structured-light
|
| 14 |
+
- phase-shifting
|
| 15 |
+
- depth-map
|
| 16 |
+
- point-cloud
|
| 17 |
+
- synthetic-dataset
|
| 18 |
+
pretty_name: ForgeOptics Structured Light Depth Samples
|
| 19 |
---
|
| 20 |
+
|
| 21 |
+

|
| 22 |
+
|
| 23 |
+
[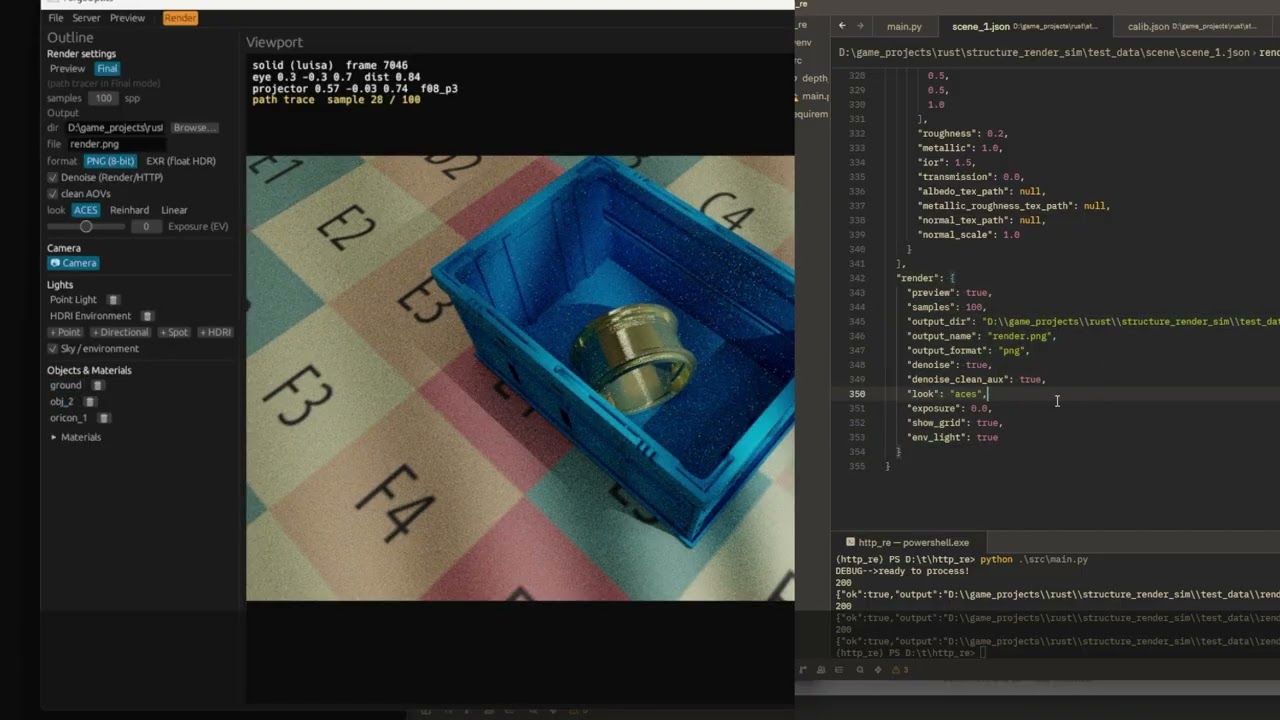](https://www.youtube.com/watch?v=JFxiePWoQpQ)
|
| 24 |
+
|
| 25 |
+
## What's Included
|
| 26 |
+
Free sample synthetic depth datasets generated deterministically using **ForgeOptics — Structured Light Depth Simulator**.
|
| 27 |
+
each sample scene folder contains the following files:
|
| 28 |
+
|
| 29 |
+
1. depth_z.exr — Raw 32-bit float metric depth map. Using camera intrinsics (calib), you can reconstruct the true 3D point cloud.
|
| 30 |
+
|
| 31 |
+
2. render.png — RGB render output.
|
| 32 |
+
|
| 33 |
+
3. seg_index.json — Object-ID segmentation mask mapping and class index metadata.
|
| 34 |
+
|
| 35 |
+
4. pointcloud_scene3.ply — Pre-reconstructed 3D point cloud (provided for Scene 3 as an example reference; other raw point clouds are excluded to keep file sizes manageable).
|
| 36 |
+
|
| 37 |
+
## Generated by ForgeOptics
|
| 38 |
+
These datasets are produced by ForgeOptics, a high-performance optical simulation engine designed for synthetic data generation.
|
| 39 |
+
Key Software Features
|
| 40 |
+
- Physically Accurate Structured Light Simulation: Simulates multi-frequency phase-shift fringe pattern projection for depth acquisition.
|
| 41 |
+
- Complex Optics Path Tracing: Accurately models optical refractions, surface caustics, metallic reflections, and PBR materials.
|
| 42 |
+
- AOV Extraction + OIDN Denoising: Extracts clean first-hit G-buffers (Albedo, Normals, Metric Depth) with Open Image Denoise.
|
| 43 |
+
- Automated Headless Integration: Runs as an HTTP microservice (--headless) for Python-driven batch generation pipelines.
|
| 44 |
+
- Multi-Format Ingestion: Direct CAD model loading (.obj, .glb, .stl).
|
| 45 |
+
|
| 46 |
+
## What Problems Does It Solve?
|
| 47 |
+
In computer vision and industrial robotics, acquiring ground-truth depth data for physical sensors is difficult, expensive, and error-prone. ForgeOptics addresses key challenges:
|
| 48 |
+
|
| 49 |
+
1. **No Sensor Noise / Calibration Overhead:** Eliminates the manual labor of capturing and labeling real-world 3D scanner data.
|
| 50 |
+
|
| 51 |
+
2. **Challenging Optical Surfaces:** Solves ground-truth depth generation for hard-to-scan materials like PBR glass, reflective metal, and dark absorbing plastics. Easily swap materials on the same geometry to generate perfect side-by-side ground-truth comparison datasets.
|
| 52 |
+
|
| 53 |
+
3. **Edge Case Dataset Expansion:** Allows rapid generation of thousands of corner-case scenes under varying light conditions and camera poses before real hardware deployment.
|
| 54 |
+
|
| 55 |
+
4. **Ideal for Vision-Language & Physical AI:** Provides perfect, pixel-aligned depth and segmentation ground truth for fine-tuning object detection, instance segmentation, and 3D pose estimation models.
|
| 56 |
+
|
| 57 |
+
## Get the App
|
| 58 |
+
To render custom depth datasets with your own CAD models on your local GPU:
|
| 59 |
+
👉 **[Buy ForgeOptics on Gumroad ($199 Perpetual License)](https://5940734191807.gumroad.com/l/eqxti)**
|
| 60 |
+
* Native **Windows** (CUDA / DX12) and **Linux** (CUDA 12 / OptiX) binaries
|
| 61 |
+
* Includes interactive GUI mode and Headless HTTP server mode (`--headless`)
|
| 62 |
+
|
| 63 |
+
### How to use:
|
| 64 |
+
`uv venv --python 3.11`
|
| 65 |
+
`uv pip install -r requirements.txt`
|
| 66 |
+
## ⚡ Quick Start & Visualization
|
| 67 |
+
|
| 68 |
+
`python ./src/main.py` -> batch process with your scene setting
|
| 69 |
+
|
| 70 |
+
`python ./src.depth_visualizer.py` -> for checkign the depth results
|
| 71 |
+
## Acknowledgments
|
| 72 |
+
This project builds upon [LuisaRender](https://github.com/LuisaRender/LuisaRender), used under the [BSD 3-Clause License](https://opensource.org/licenses/BSD-3-Clause). Copyright (c) LuisaGroup.
|