

Add Touch-R1 model card and NeurIPS citation
Browse files
README.md
ADDED
|
@@ -0,0 +1,69 @@
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
| 1 |
+
---
|
| 2 |
+
pipeline_tag: image-text-to-text
|
| 3 |
+
datasets:
|
| 4 |
+
- laiyingxin/TouchReason
|
| 5 |
+
tags:
|
| 6 |
+
- tactile-reasoning
|
| 7 |
+
- multimodal
|
| 8 |
+
- physical-reasoning
|
| 9 |
+
- reinforcement-learning
|
| 10 |
+
- robotics
|
| 11 |
+
- arxiv:2605.27154
|
| 12 |
+
---
|
| 13 |
+
|
| 14 |
+
# Touch-R1
|
| 15 |
+
|
| 16 |
+
### Reinforcing Touch Reasoning in MLLMs
|
| 17 |
+
|
| 18 |
+
[Paper](https://arxiv.org/abs/2605.27154) · [Project Page](https://laiyingxin2.github.io/Touch-R1/) · [GitHub](https://github.com/laiyingxin2/Touch-R1) · [TouchReason Dataset](https://huggingface.co/datasets/laiyingxin/TouchReason)
|
| 19 |
+
|
| 20 |
+
**Touch-R1 brings explicit reasoning to physical contact.** It connects optical tactile observations with vision and language, enabling multimodal models to use contact evidence when judging physical properties and revising misleading visual impressions.
|
| 21 |
+
|
| 22 |
+
> **Release status:** Model card available. Model weights and verified inference instructions are coming soon. The GitHub repository currently hosts the project website; research code is forthcoming.
|
| 23 |
+
|
| 24 |
+
|
| 25 |
+
|
| 26 |
+
## Model Summary
|
| 27 |
+
|
| 28 |
+
| Item | Description |
|
| 29 |
+
| :--- | :--- |
|
| 30 |
+
| Model type | Tactile reasoning multimodal large language model |
|
| 31 |
+
| Backbone reported in the paper | Qwen2.5-VL-7B |
|
| 32 |
+
| Research data | TouchReason-1M and TouchReason-Bench |
|
| 33 |
+
| Inputs | Optical tactile observations, visual context, and language questions |
|
| 34 |
+
| Outputs | Structured textual reasoning and physical-property judgments |
|
| 35 |
+
|
| 36 |
+
## Approach
|
| 37 |
+
|
| 38 |
+
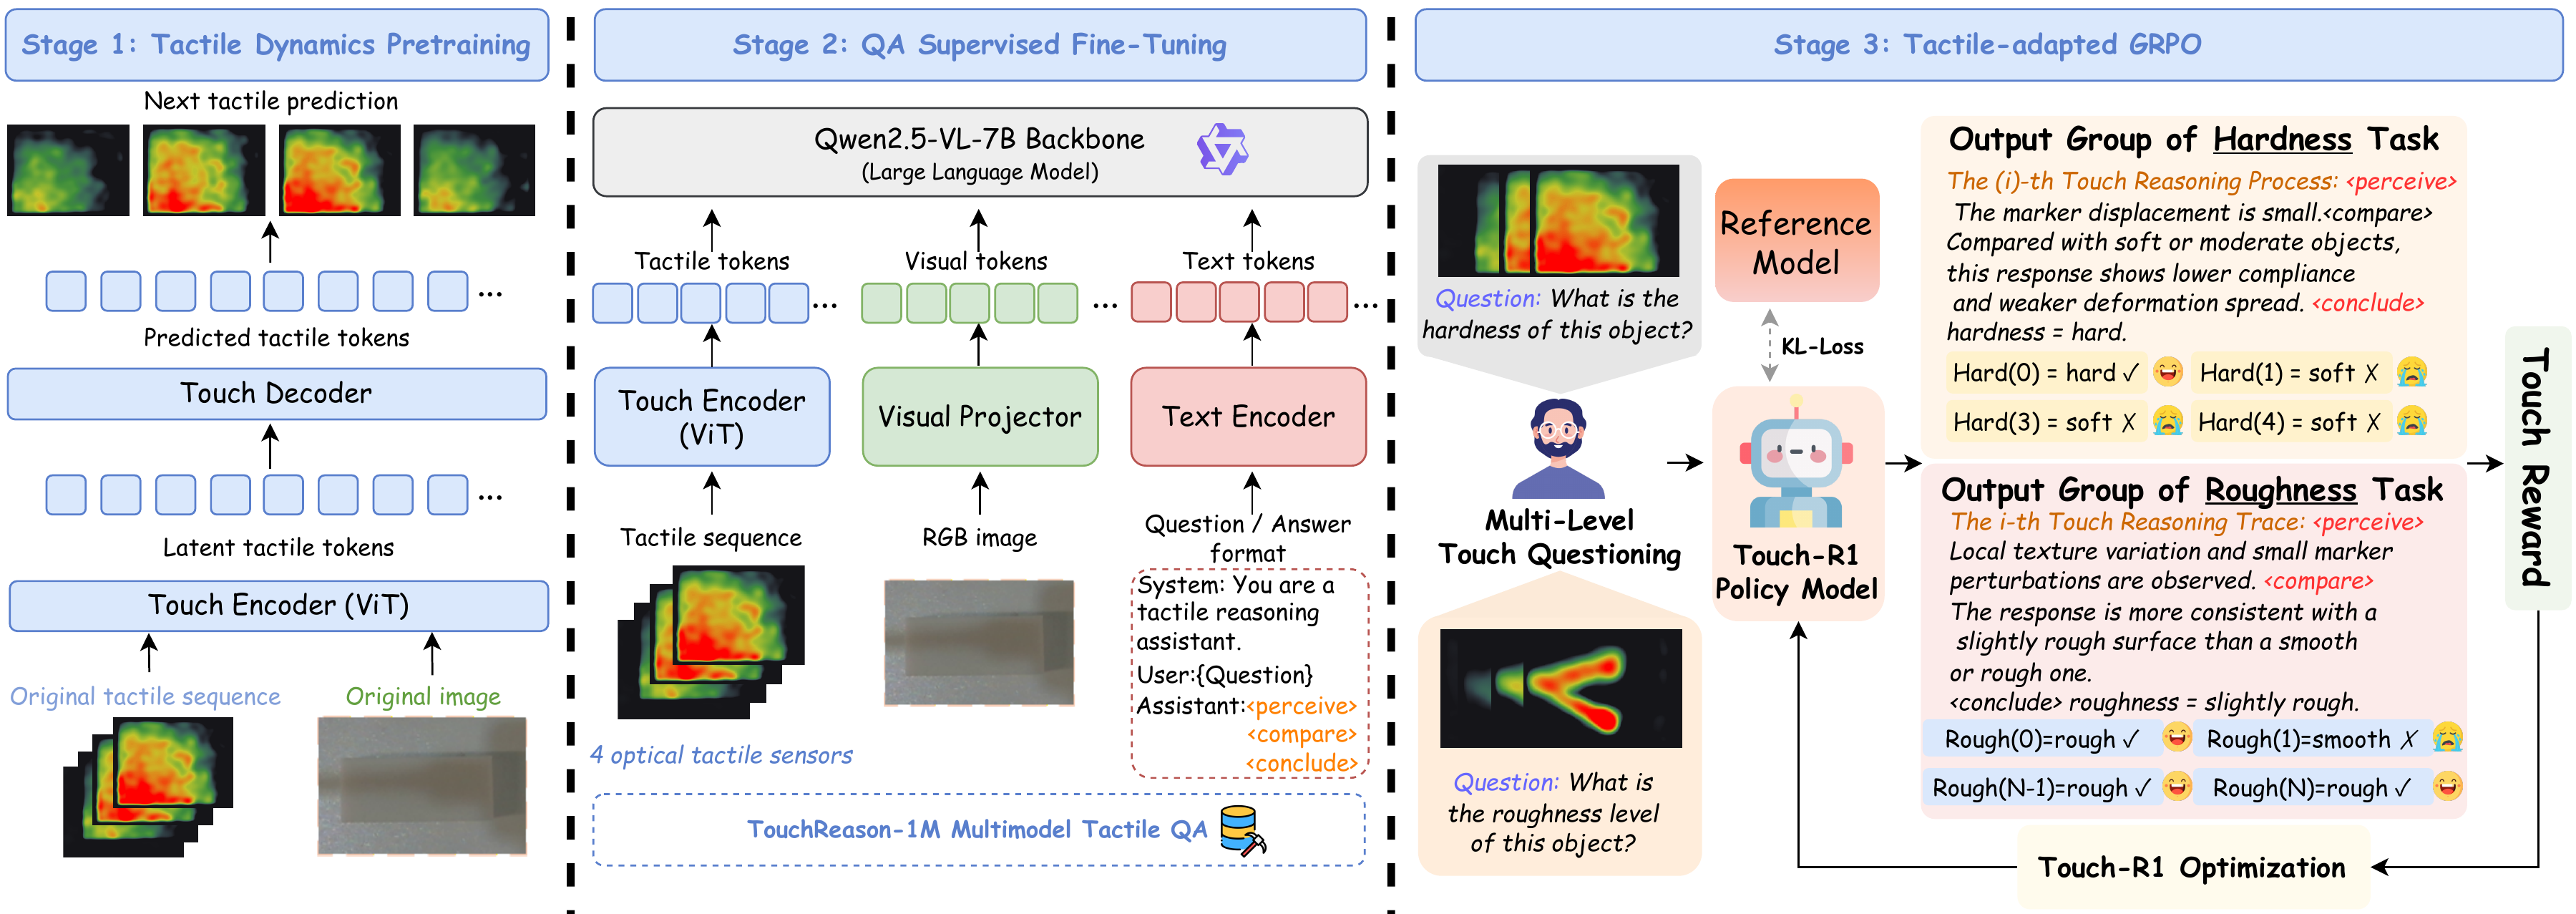
The training pipeline combines three stages:
|
| 39 |
+
|
| 40 |
+
1. **Tactile dynamics pretraining** learns contact-sensitive representations by predicting future tactile tokens.
|
| 41 |
+
2. **QA supervised fine-tuning** aligns touch, vision, and language with structured reasoning.
|
| 42 |
+
3. **Tactile-grounded GRPO** combines ordinal-aware accuracy, cross-sensor physical consistency, and structured-format rewards with an input-side tactile grounding objective.
|
| 43 |
+
|
| 44 |
+
Responses organize evidence through `<perceive>`, `<compare>`, and `<conclude>` stages. Counterfactual tactile inputs—removed, shuffled, or noise-masked—help identify predictions that depend on genuine contact evidence.
|
| 45 |
+
|
| 46 |
+
## Research Use
|
| 47 |
+
|
| 48 |
+
Touch-R1 is designed for physical-property inference, ordinal comparison, cross-sensor reasoning, and visual–tactile conflict resolution. Its intended interface is tactile/visual question answering with structured textual judgments.
|
| 49 |
+
|
| 50 |
+
The paper reports a **60.1 average score** for Touch-R1-7B on TouchReason-Bench. See the [paper](https://arxiv.org/abs/2605.27154) for the evaluation protocol and complete results.
|
| 51 |
+
|
| 52 |
+
## Related Resources
|
| 53 |
+
|
| 54 |
+
- **Dataset:** [TouchReason](https://huggingface.co/datasets/laiyingxin/TouchReason)
|
| 55 |
+
- **Project page:** [Method, acquisition videos, and object atlas](https://laiyingxin2.github.io/Touch-R1/)
|
| 56 |
+
- **Project repository:** [Touch-R1](https://github.com/laiyingxin2/Touch-R1)
|
| 57 |
+
|
| 58 |
+
## Citation
|
| 59 |
+
|
| 60 |
+
```bibtex
|
| 61 |
+
@inproceedings{lai2026touchr1reinforcingtouchreasoning,
|
| 62 |
+
title = {{Touch-R1}: Reinforcing Touch Reasoning in {MLLMs}},
|
| 63 |
+
author = {Yingxin Lai and Yafei Zhou and Fucai Zhu and Siyu Zhu and Weihao Yuan},
|
| 64 |
+
booktitle = {Advances in Neural Information Processing Systems},
|
| 65 |
+
year = {2026},
|
| 66 |
+
note = {To appear},
|
| 67 |
+
url = {https://arxiv.org/abs/2605.27154}
|
| 68 |
+
}
|
| 69 |
+
```
|