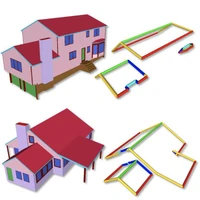
| import trimesh |
| import numpy as np |
| from copy import deepcopy |
| from PIL import Image |
|
|
| from . import color_mappings |
|
|
| def line(p1, p2, c=(255,0,0), resolution=10, radius=0.05): |
| '''draws a 3d cylinder along the line (p1, p2)''' |
| |
| if len(c) == 1: |
| c = [c[0]]*4 |
| elif len(c) == 3: |
| c = [*c, 255] |
| elif len(c) != 4: |
| raise ValueError(f'{c} is not a valid color (must have 1,3, or 4 elements).') |
| |
| |
| p1, p2 = np.asarray(p1), np.asarray(p2) |
| l = np.linalg.norm(p2-p1) |
| |
| direction = (p2 - p1) / l |
| |
| |
| T = np.eye(4) |
| T[:3, 2] = direction |
| T[:3, 3] = (p1+p2)/2 |
| |
| |
| b0, b1 = T[:3, 0], T[:3, 1] |
| if np.abs(np.dot(b0, direction)) < np.abs(np.dot(b1, direction)): |
| T[:3, 1] = -np.cross(b0, direction) |
| else: |
| T[:3, 0] = np.cross(b1, direction) |
| |
| |
| mesh = trimesh.primitives.Cylinder(radius=radius, height=l, transform=T) |
| |
| |
| mesh.visual.vertex_colors = np.ones_like(mesh.visual.vertex_colors)*c |
| |
| return mesh |
|
|
| def show_wf(row, radius=10): |
| EDGE_CLASSES = ['eave', |
| 'ridge', |
| 'step_flashing', |
| 'rake', |
| 'flashing', |
| 'post', |
| 'valley', |
| 'hip', |
| 'transition_line'] |
| return [line(a,b, radius=radius, c=color_mappings.gestalt_color_mapping[EDGE_CLASSES[cls_id]]) for (a,b), cls_id in zip(np.stack([*row['wf_vertices']])[np.stack(row['wf_edges'])], row['edge_semantics'])] |
| |
|
|
|
|
| def show_grid(edges, meshes=None, row_length=5): |
| ''' |
| edges: list of list of meshes |
| meshes: optional corresponding list of meshes |
| row_length: number of meshes per row |
| |
| returns trimesh.Scene() |
| ''' |
| |
| T = np.eye(4) |
| out = [] |
| edges = [sum(e[1:], e[0]) for e in edges] |
| row_height = 1.1 * max((e.extents for e in edges), key=lambda e: e[1])[1] |
| col_width = 1.1 * max((e.extents for e in edges), key=lambda e: e[0])[0] |
| |
| |
| if meshes is None: |
| meshes = [None]*len(edges) |
|
|
| for i, (gt, mesh) in enumerate(zip(edges, meshes), start=0): |
| mesh = deepcopy(mesh) |
| gt = deepcopy(gt) |
|
|
| if i%row_length != 0: |
| T[0, 3] += col_width |
|
|
| else: |
| T[0, 3] = 0 |
| T[1, 3] += row_height |
|
|
| |
| |
| if mesh is not None: |
| mesh.apply_transform(T) |
| out.append(mesh) |
| |
| gt.apply_transform(T) |
| out.append(gt) |
| |
| |
| out.extend([mesh, gt]) |
|
|
| |
| return trimesh.Scene(out) |
|
|
|
|
|
|
|
|
| def visualize_order_images(row_order): |
| return create_image_grid(row_order['ade20k'] + row_order['gestalt'] + [visualize_depth(dm) for dm in row_order['depthcm']], num_per_row=len(row_order['ade20k'])) |
|
|
| def create_image_grid(images, target_length=312, num_per_row=2): |
| |
| first_img = images[0] |
| aspect_ratio = first_img.width / first_img.height |
| new_width = int((target_length ** 2 * aspect_ratio) ** 0.5) |
| new_height = int((target_length ** 2 / aspect_ratio) ** 0.5) |
| |
| |
| resized_images = [img.resize((new_width, new_height), Image.Resampling.LANCZOS) for img in images] |
| |
| |
| num_rows = (len(resized_images) + num_per_row - 1) // num_per_row |
| grid_width = new_width * num_per_row |
| grid_height = new_height * num_rows |
| |
| |
| grid_img = Image.new('RGB', (grid_width, grid_height)) |
| |
| |
| for i, img in enumerate(resized_images): |
| x_offset = (i % num_per_row) * new_width |
| y_offset = (i // num_per_row) * new_height |
| grid_img.paste(img, (x_offset, y_offset)) |
| |
| return grid_img |
|
|
|
|
| import matplotlib.pyplot as plt |
|
|
| def visualize_depth(depth, min_depth=None, max_depth=None, cmap='rainbow'): |
| depth = np.array(depth) |
| |
| if min_depth is None: |
| min_depth = np.min(depth) |
| if max_depth is None: |
| max_depth = np.max(depth) |
| |
| |
| |
| depth = (depth - min_depth) / (max_depth - min_depth) |
| depth = np.clip(depth, 0, 1) |
| |
| |
| cmap = plt.get_cmap(cmap) |
| depth_image = (cmap(depth) * 255).astype(np.uint8) |
| |
| |
| depth_image = Image.fromarray(depth_image) |
| |
| return depth_image |