

license: cc-by-4.0
tags:
  - autonomous-driving
  - navsim
  - end-to-end-planning
  - drive-jepa
  - single-camera
FrontDrive — single-front-camera NAVSIM planners (Drive-JEPA perception-based, continued on all of navtrain)
Three checkpoints of the same recipe (three seeds), submitted together to the NAVSIM v1 navtest leaderboard as a multi-seed entry. Each is the released Drive-JEPA perception-based ViT-L checkpoint continued for 5 epochs on all 1,192 navtrain logs (train + val, 103,288 samples) with Adam 3e-5 (backbone 0.1×), cosine decay to 3e-6 after 200 warm-up steps, effective batch 64, and the five per-epoch fp16 exports averaged into one weight soup. Input: the front camera only (CAM_F0 at t and t−0.5 s, 512×256) plus the ego status; the side cameras are used only through their calibration (no side-camera pixels). Output: one trajectory per scene.
| file | seed | navtest PDMS | sha256 (prefix) |
|---|---|---|---|
pb_off_ft_all_s0_soup_1_5.ckpt |
0 | 93.86 | ac0331f9a5d44ec1 |
pb_off_ft_all_s1_soup_1_5.ckpt |
1 | 93.78 | c7cb6ca5617cdb8f |
pb_off_ft_all_s2_soup_1_5.ckpt |
2 | 93.94 | fc0ca06034e85939 |
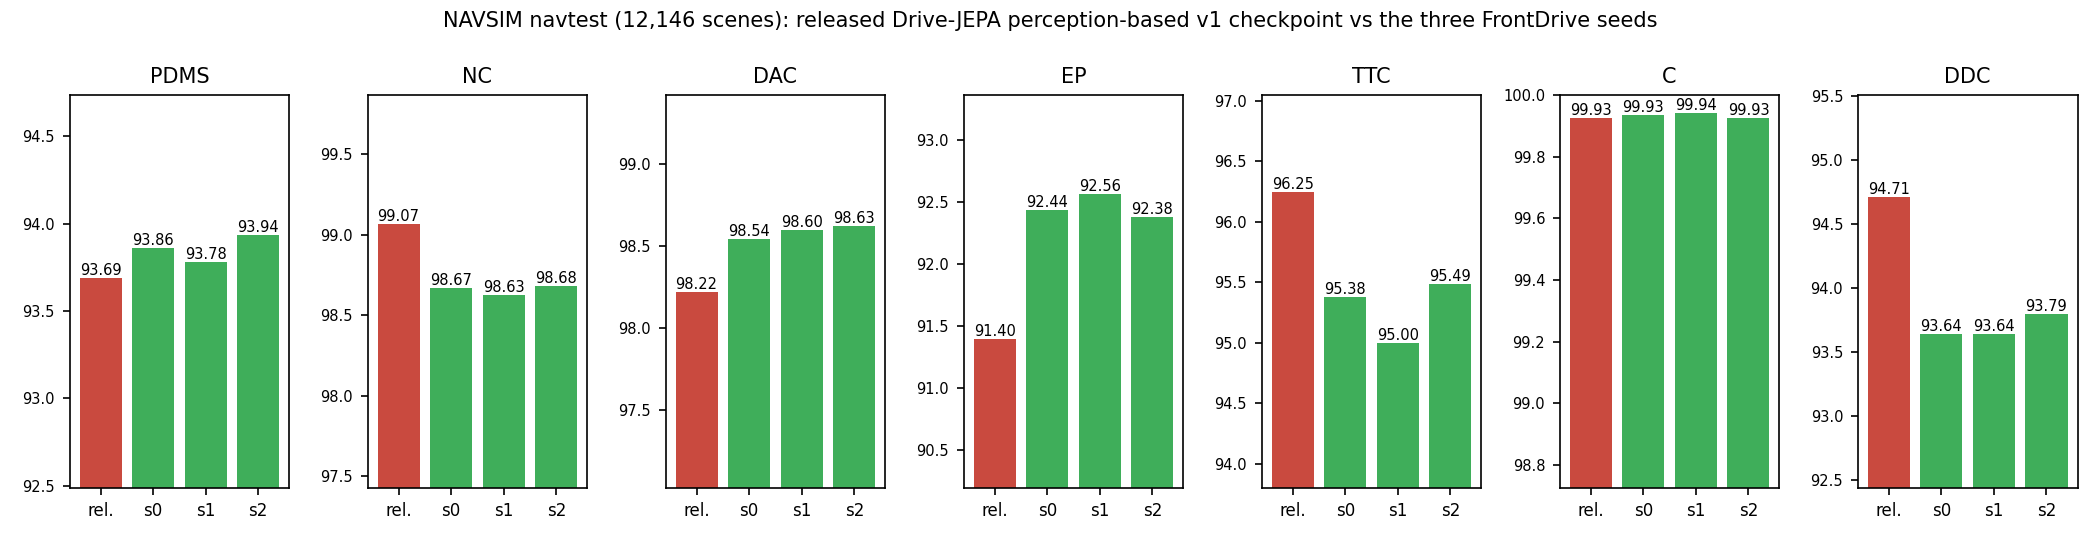
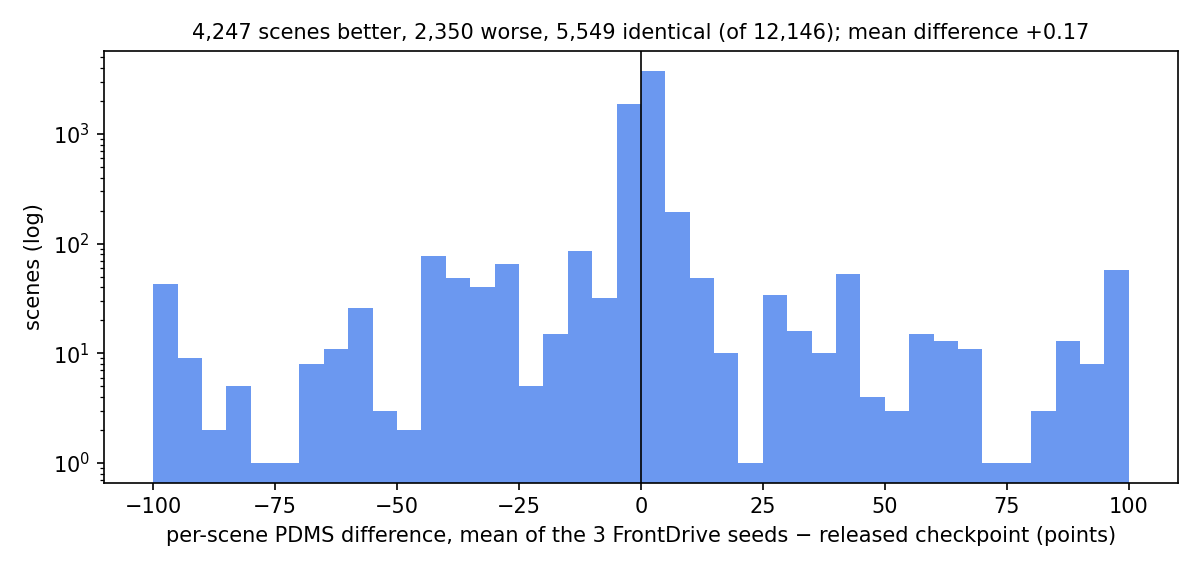
Mean 93.86 (SD 0.08). The released Drive-JEPA checkpoint scores 93.69 with the same evaluation code; our from-scratch baseline (e50 encoder, upstream recipe, dev-selected) 93.50. Sub-scores relative to the released checkpoint: more ego progress (+1.0), higher drivable-area compliance (+0.35), slightly lower no-at-fault-collision (−0.4), TTC (−0.8…−1.2) and driving-direction (−1.0).
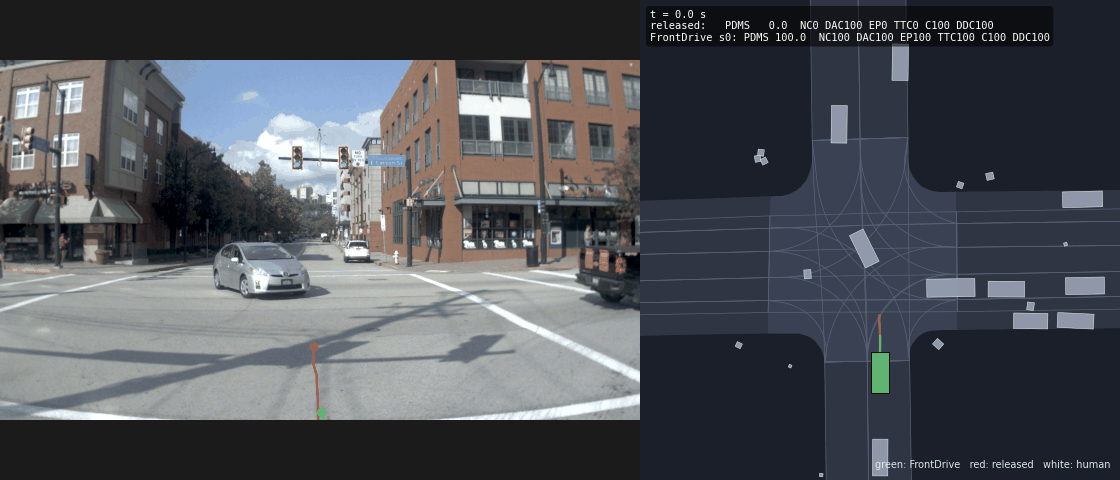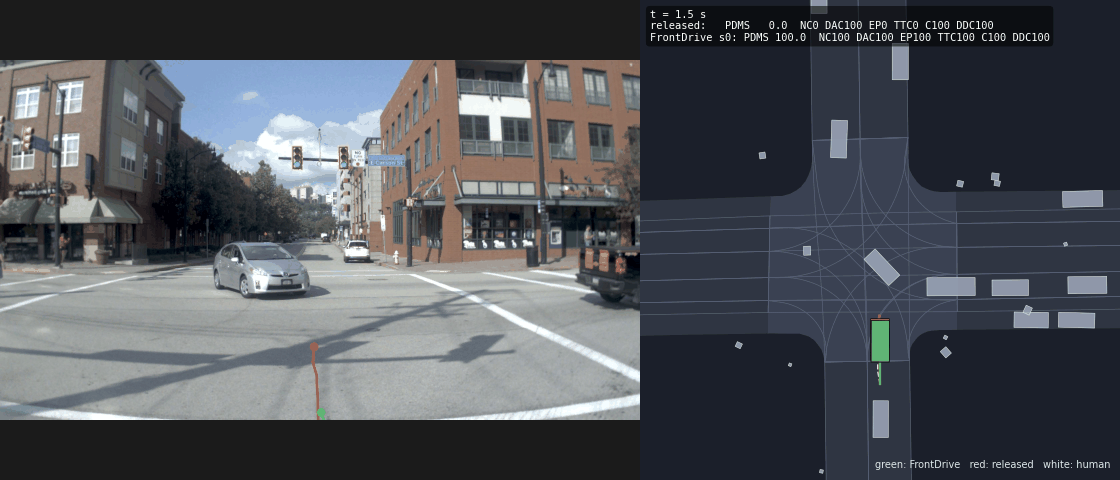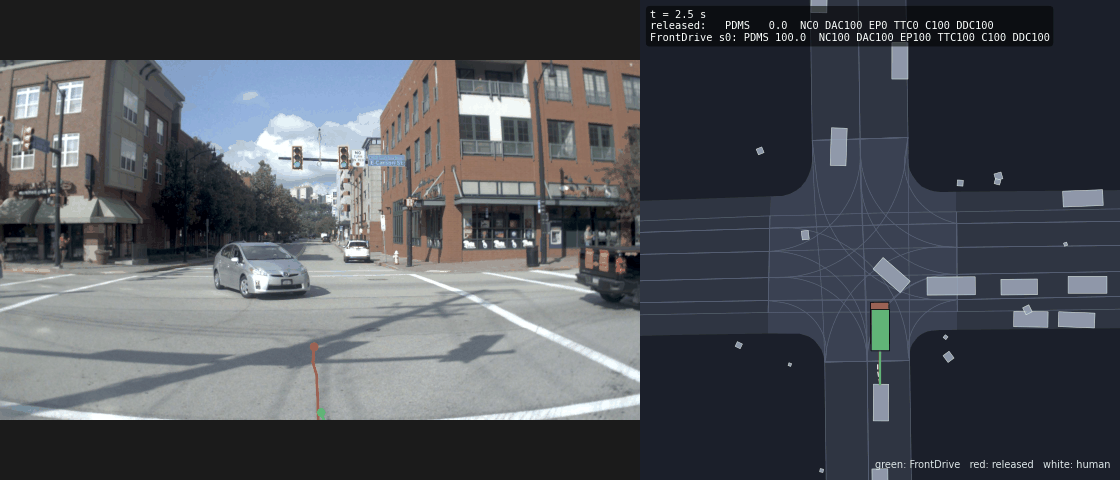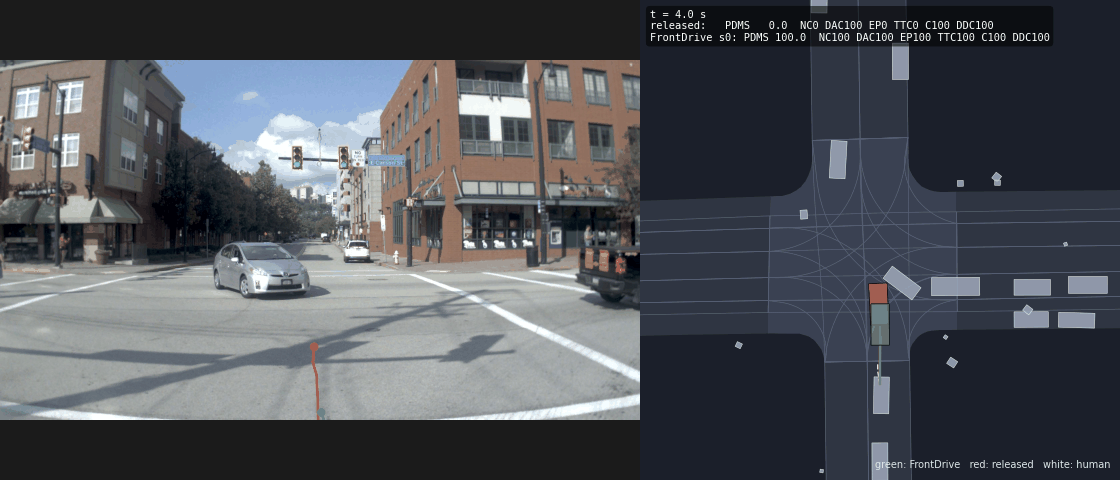
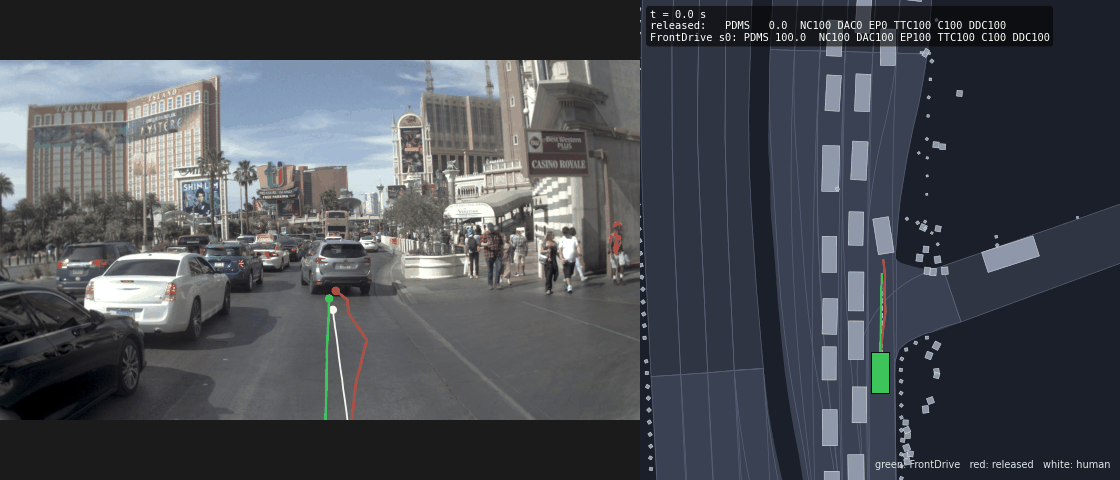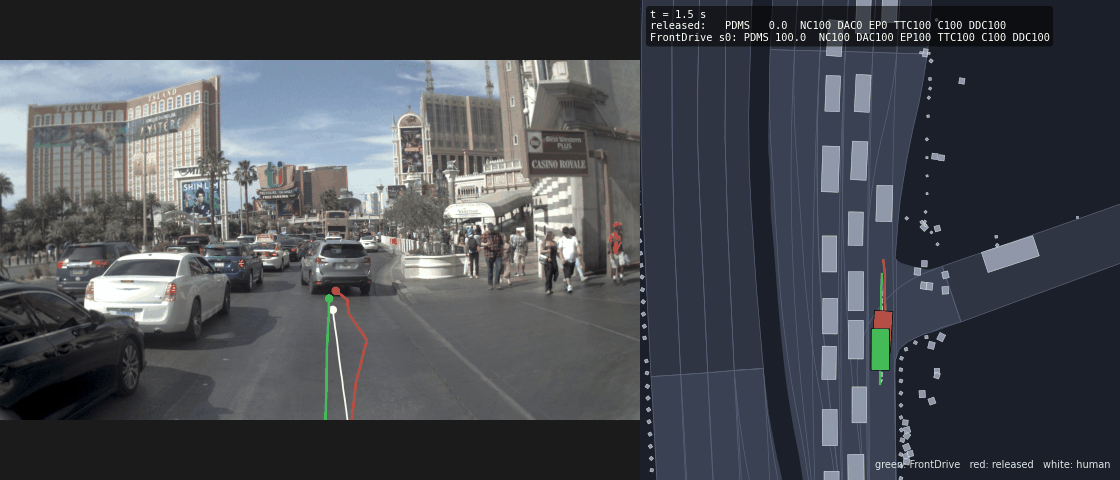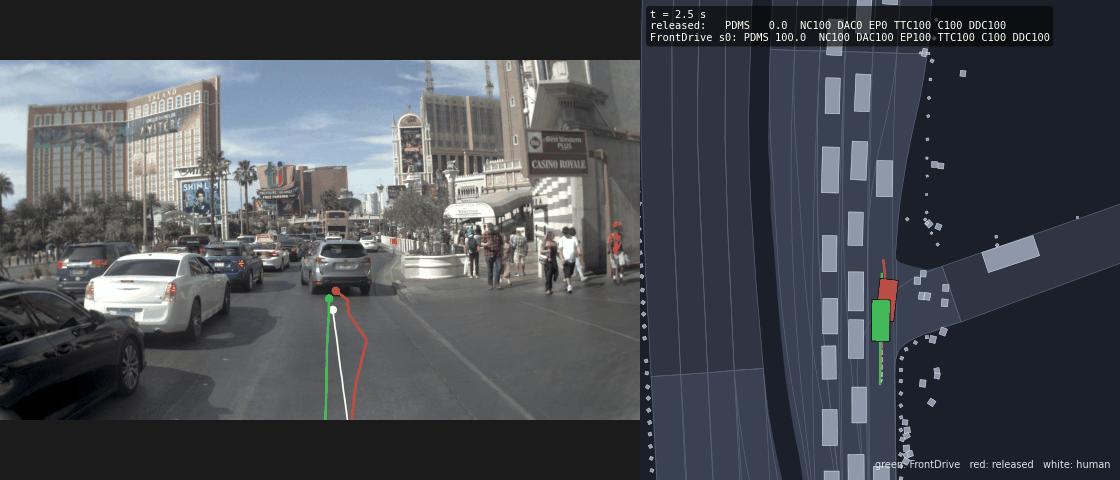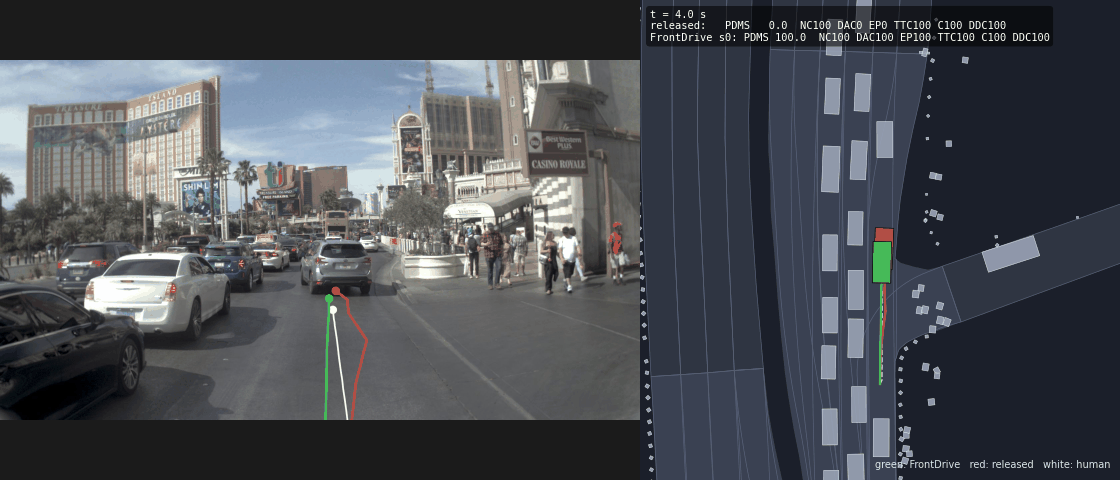
Where the FrontDrive models do better than the released checkpoint
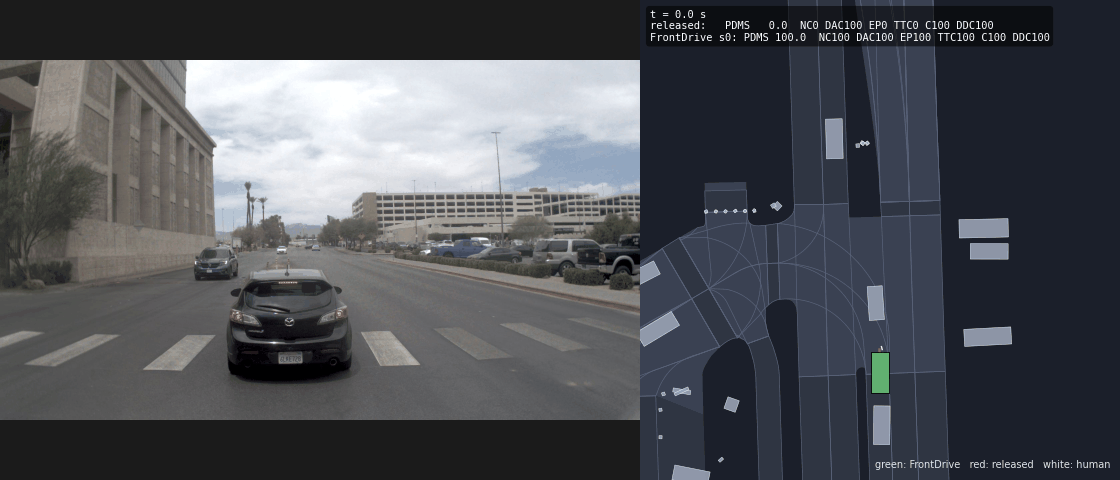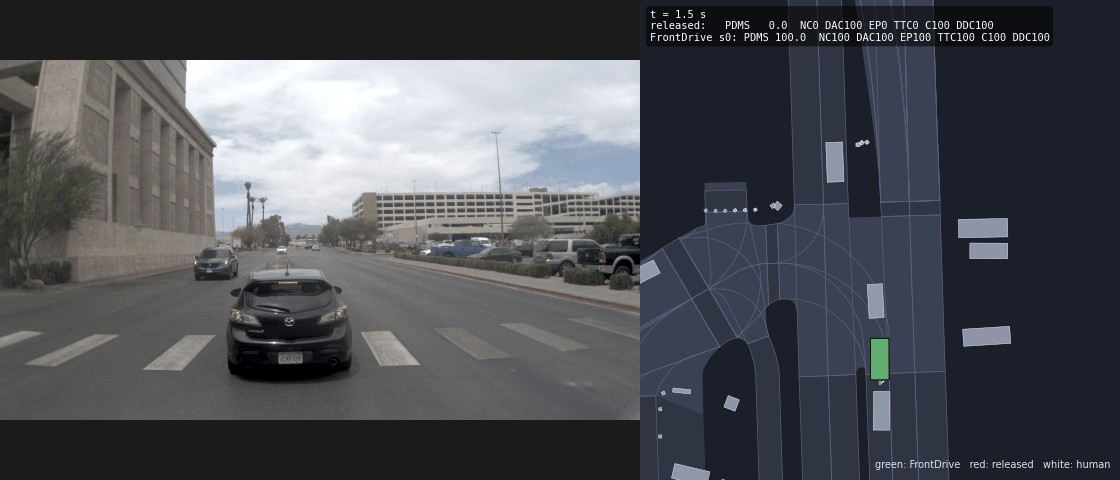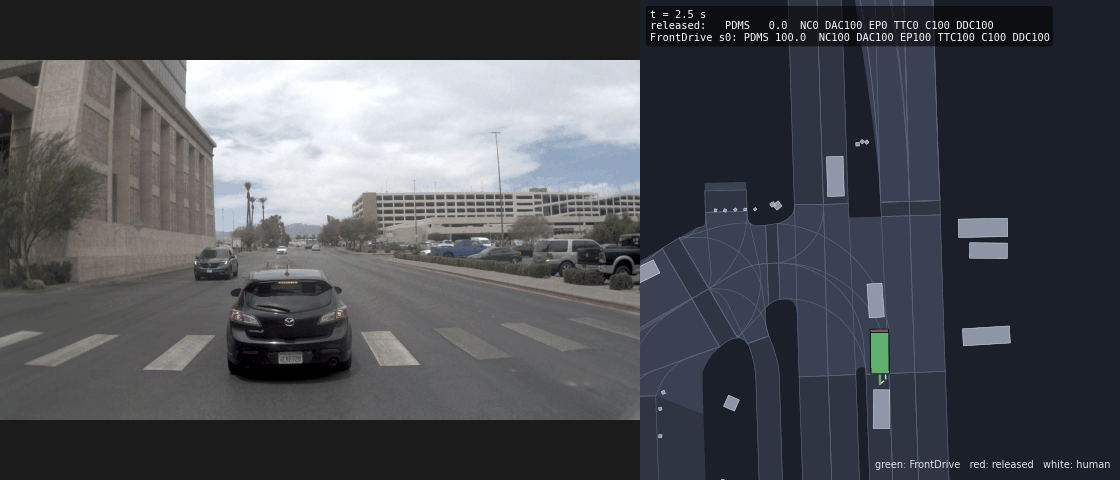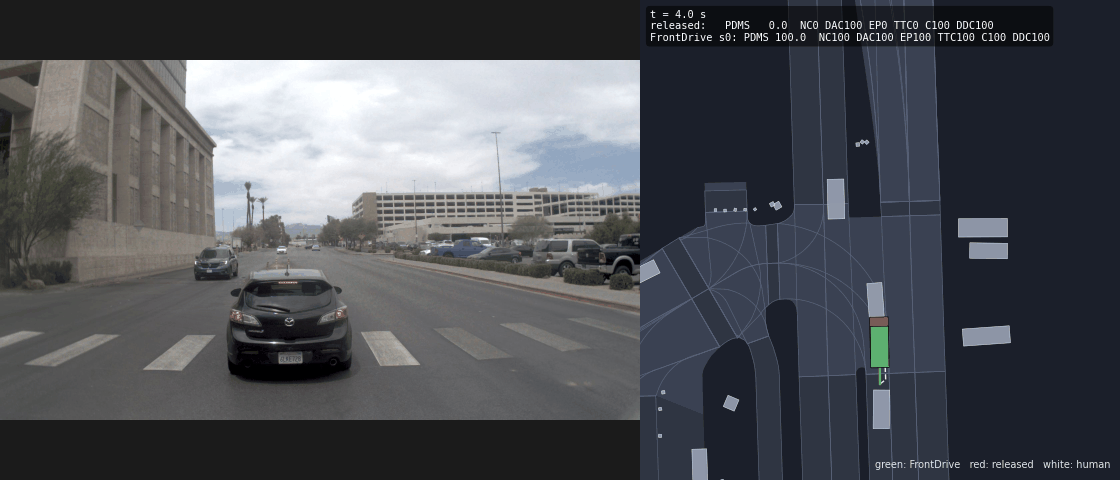
| released checkpoint rolls into the stopped car ahead | released checkpoint rolls into the crossing car |
|---|---|
 |
 |
| released checkpoint leaves the drivable area (curb) | released checkpoint veers off the road |
|---|---|
 |
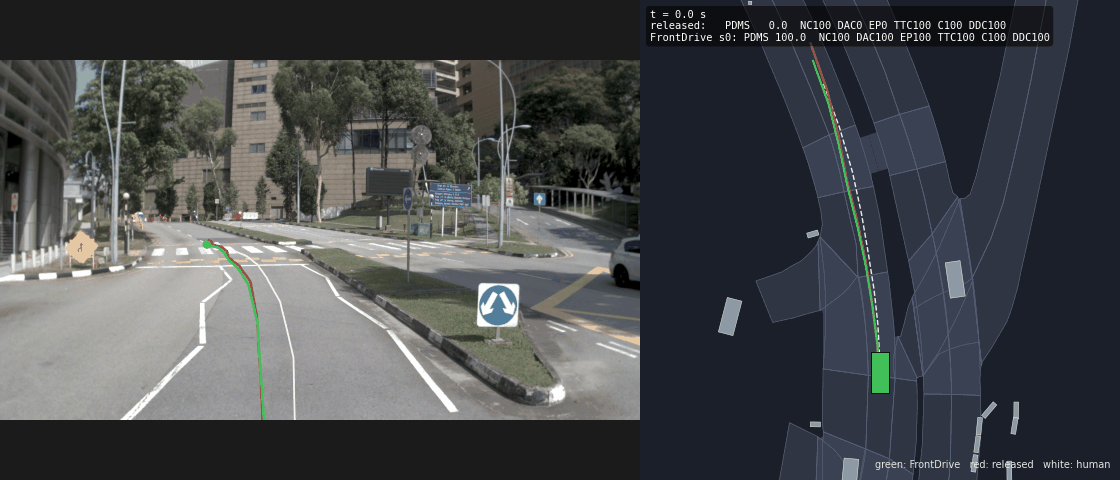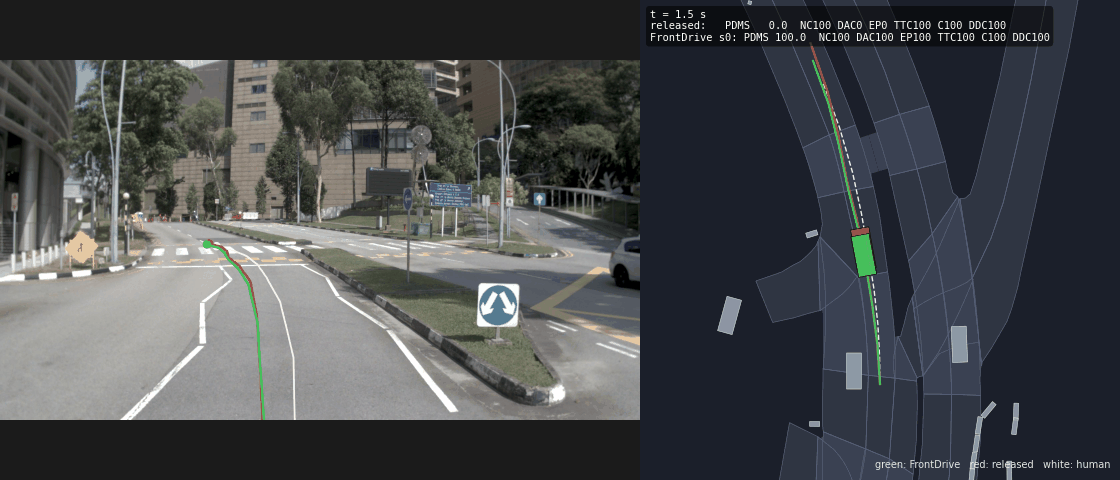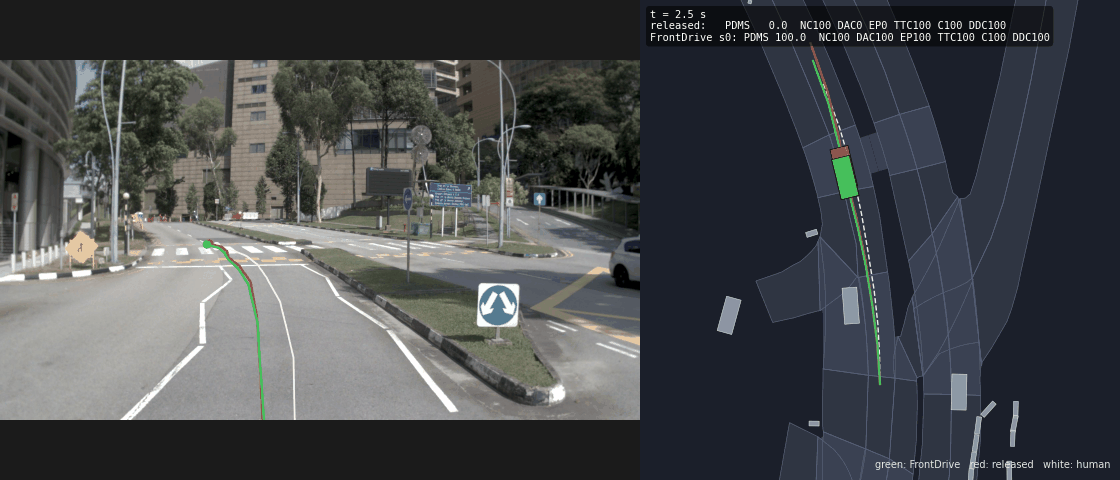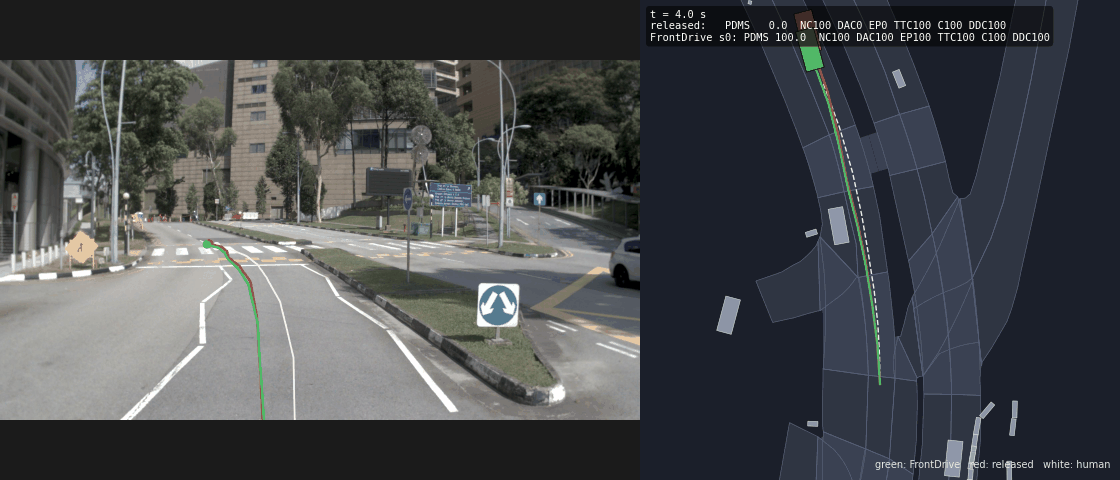 |
Green: FrontDrive seed 0; red: released Drive-JEPA checkpoint; white dashed: human driver. Rendered from the navtest metric cache and
the two models' trajectories by frontdrive/viz/navtest_showcase.py in the code repository (images are hosted there).
Loading. Each file is a Lightning-style state dict ({"state_dict": {"agent._pad_model.*": …}}, fp16) that
DriveJEPAAgent.initialize() loads when passed as agent.checkpoint_path (navsim v1 config
agent=drive_jepa_perception_based_agent agent.config.latent=False +agent.config.side_cams_from_calibration=true). Code, patches
and the exact training / evaluation scripts: https://github.com/WangYuHang-cmd/FrontDrive
Provenance. Derived from LinhanWang/Drive-JEPA drive_jepa_perception_based_agent_vitl.ckpt (Drive-JEPA, Apache-2.0 code)
and trained only on public NAVSIM navtrain data; navtest was never used for training or model selection.