


CaiYuanhao/HDR-GS
Updated • 1
image image | label class label |
|---|---|
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images | |
1input_images |


High dynamic range · Exposure control · Gaussian splatting · Novel view synthesis
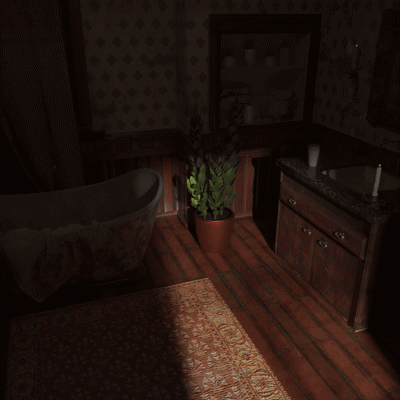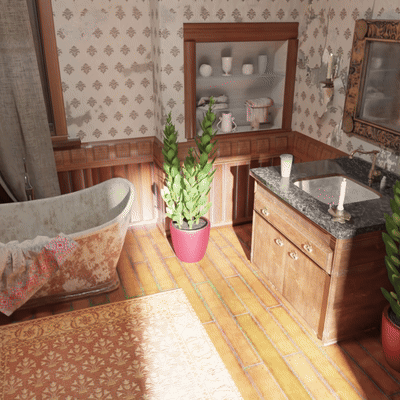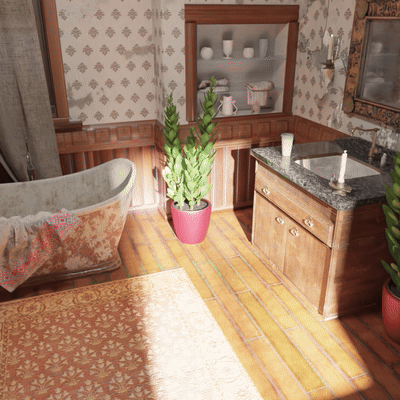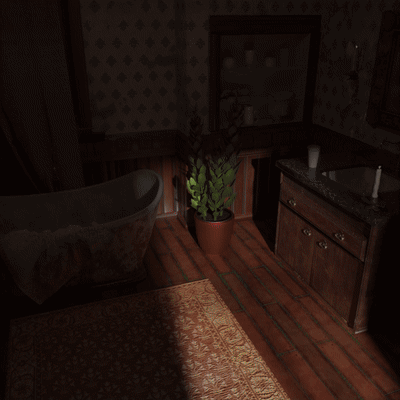 |
 |
 |
Bathroom |
Chair |
Dog |
 |
 |
 |
Bear |
Desk |
Sponza |
Demonstrations from the official HDR-GS project repository.
This repository hosts the recalibrated and reorganized HDR-GS dataset, released with the NeurIPS 2024 paper. It contains multi-view, multi-exposure images, recalibrated camera parameters, and initial point clouds for Gaussian splatting-based HDR novel view synthesis.
The original scenes come from HDR-NeRF. HDR-GS applies Structure-from-Motion to recalibrate camera poses and generate initial point clouds, and reorganizes the data for its training pipeline. See the official data preparation documentation.
The release includes 12 scenes, 2,100 LDR images, and 280 synthetic HDR reference images. The data files total approximately 3.69 GB, excluding repository metadata and this card.
| Subset | Scenes | LDR images per scene | HDR references per scene |
|---|---|---|---|
| Synthetic | bathroom, bear, chair, desk, diningroom, dog, sofa, sponza | 175 PNG images | 35 EXR images |
| Real | box, computer, flower, luckycat | 175 JPG images | — |
Each scene has 35 view identifiers and five exposure variants per view. The exposure suffix identifies an exposure setting, rather than an independent camera viewpoint. Counts above describe the files available in this release.
synthetic/ and real/ are directly at the Hugging Face repository root; there is no enclosing data_hdr/ directory.
HDR-GS/
├── synthetic/
│   ├── bathroom/
│   │   ├── images/               # 175 LDR PNG images
│   │   │   ├── 0_0.png
│   │   │   ├── 0_1.png
│   │   │   └── ...
│   │   ├── exr/                  # 35 HDR reference images
│   │   │   ├── 0.exr
│   │   │   └── ...
│   │   └── sparse/0/
│   │       ├── cameras.bin
│   │       ├── images.bin
│   │       ├── points3D.bin
│   │       ├── points3D.ply
│   │       └── project.ini
│   ├── bear/
│   ├── chair/
│   ├── desk/
│   ├── diningroom/
│   ├── dog/
│   ├── sofa/
│   └── sponza/
└── real/
    ├── box/
    │   ├── input_images/         # 175 LDR JPG images
    │   │   ├── 000_0.jpg
    │   │   ├── 000_1.jpg
    │   │   └── ...
    │   ├── poses_bounds_exps.npy
    │   └── sparse/0/             # Camera calibration and point cloud files
    ├── computer/
    ├── flower/
    └── luckycat/
| Files | Contents |
|---|---|
images/<view>_<exposure>.png |
Synthetic LDR observations at different exposure settings. |
exr/<view>.exr |
Synthetic HDR reference for the corresponding view. |
input_images/<view>_<exposure>.jpg |
Real multi-exposure LDR observations. |
cameras.bin, images.bin |
COLMAP camera intrinsics and registered image poses. |
points3D.bin, points3D.ply |
Initial sparse scene point clouds. |
poses_bounds_exps.npy |
Real-scene pose, bounds, and exposure metadata. |
project.ini |
COLMAP project configuration. |
The official dataset loader defines exposure handling and evaluation splits. For synthetic images, it maps exposure indices 0–4 to [0.125, 0.5, 2.0, 8.0, 32.0]. Training and evaluation images are selected by the loader; they are not stored as separate train/test directories. Use the released scene configurations and --eval when reproducing the project's evaluation.
pip install huggingface_hub
Run from the HDR-GS project root to reproduce the directory expected by the code:
from huggingface_hub import snapshot_download

snapshot_download(
    repo_id="CaiYuanhao/HDR-GS",
    repo_type="dataset",
    allow_patterns=["synthetic/**", "real/**"],
    local_dir="data_hdr",
)
This creates data_hdr/synthetic/ and data_hdr/real/ locally. The wrapper directory is chosen by local_dir, not included in the remote data paths.
To download only the bathroom scene:
from huggingface_hub import snapshot_download

snapshot_download(
    repo_id="CaiYuanhao/HDR-GS",
    repo_type="dataset",
    allow_patterns=["synthetic/bathroom/**"],
    local_dir="data_hdr",
)
Set up the official code and environment, then train a scene:
# Synthetic scene
python3 train_synthetic.py --config config/bathroom.yaml --eval --gpu_id 0 --syn

# Real scene (download real/flower first)
python3 train_real.py --config config/flower.yaml --eval --gpu_id 0
Pretrained examples and loading instructions are available in the HDR-GS model repository.
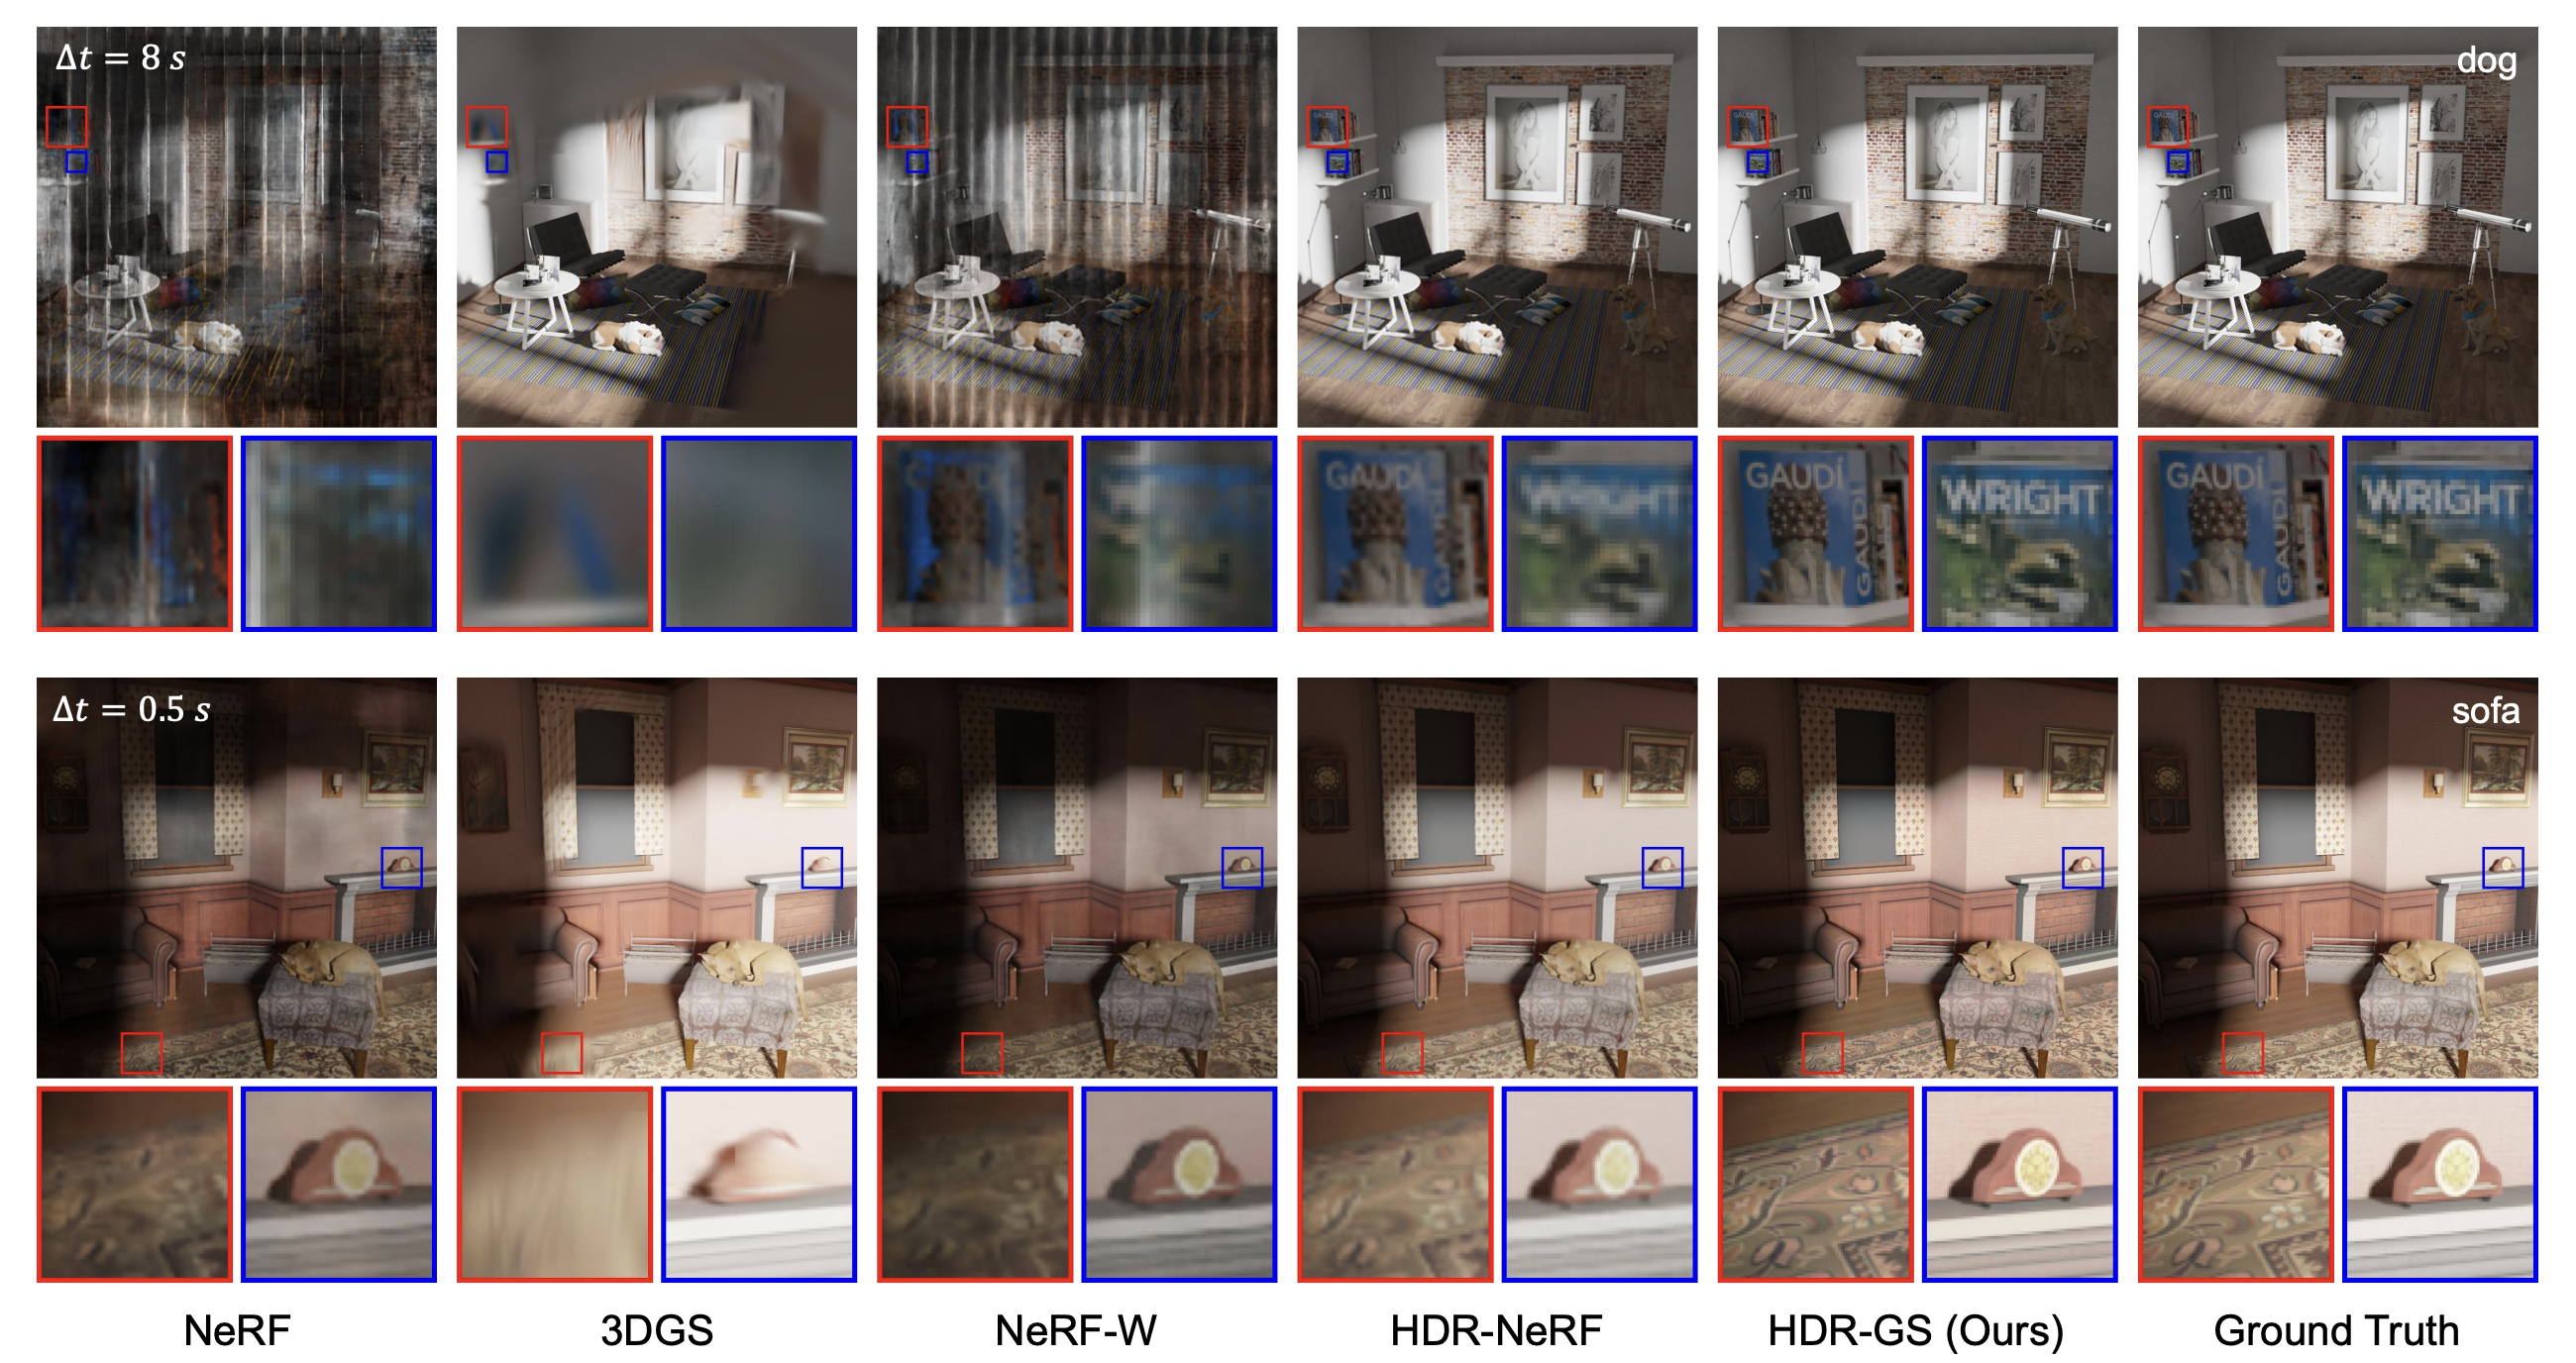
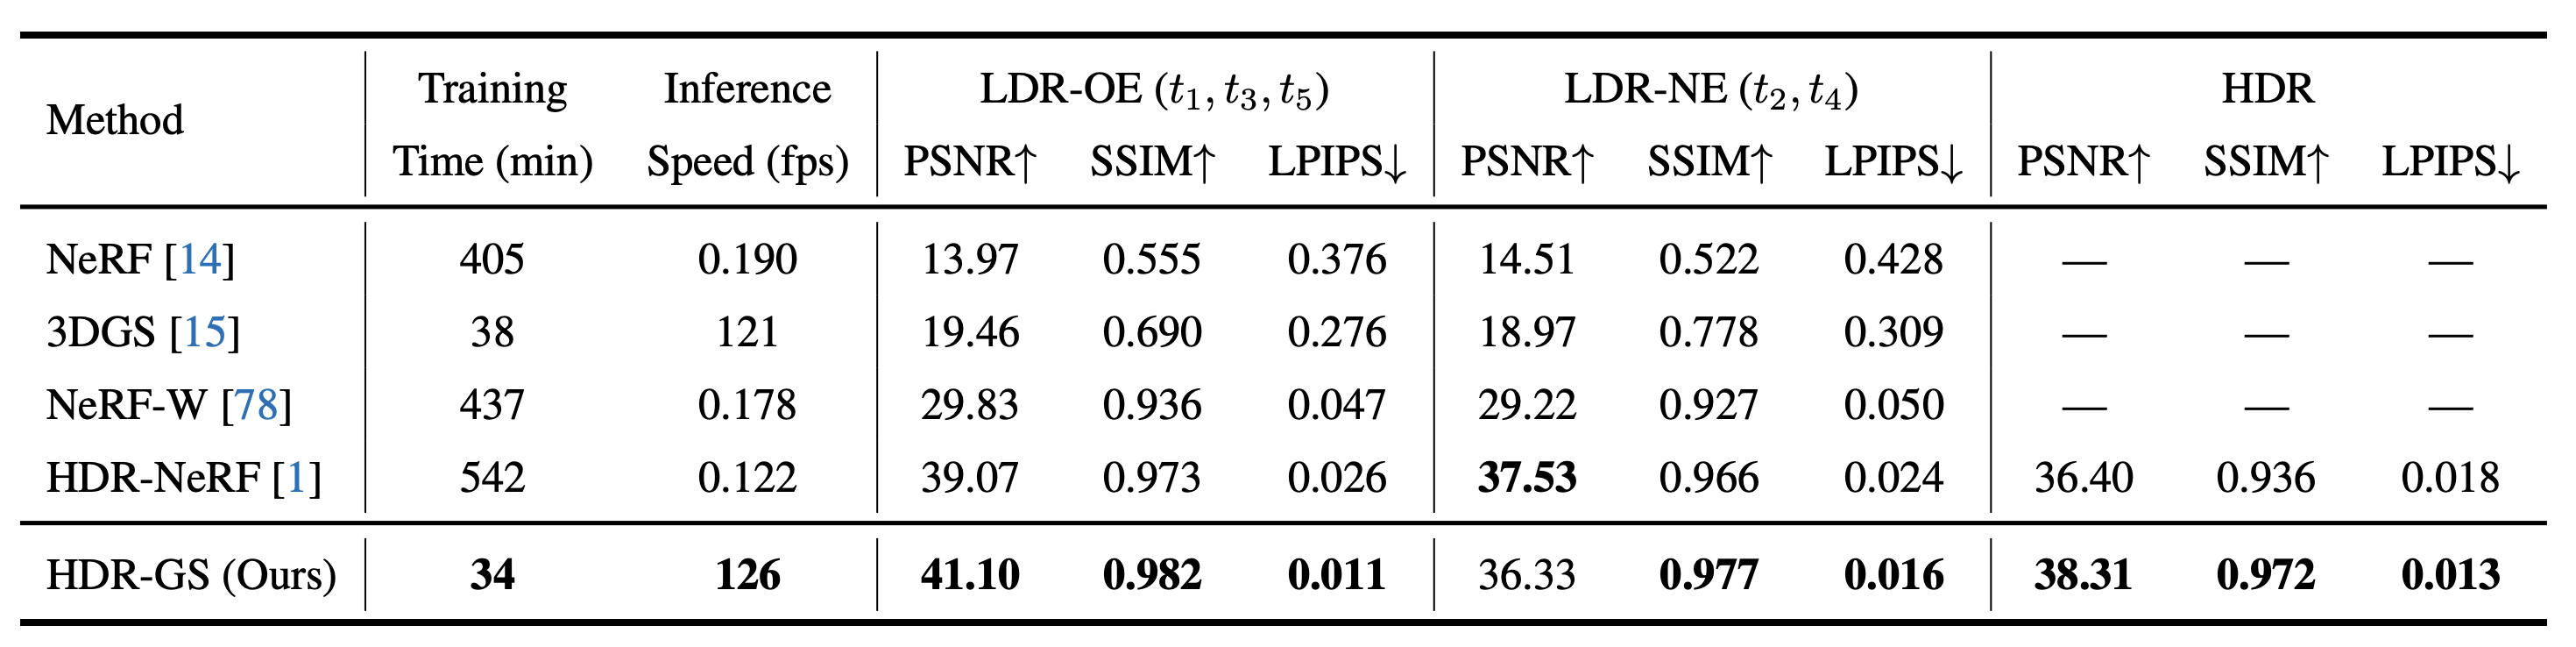
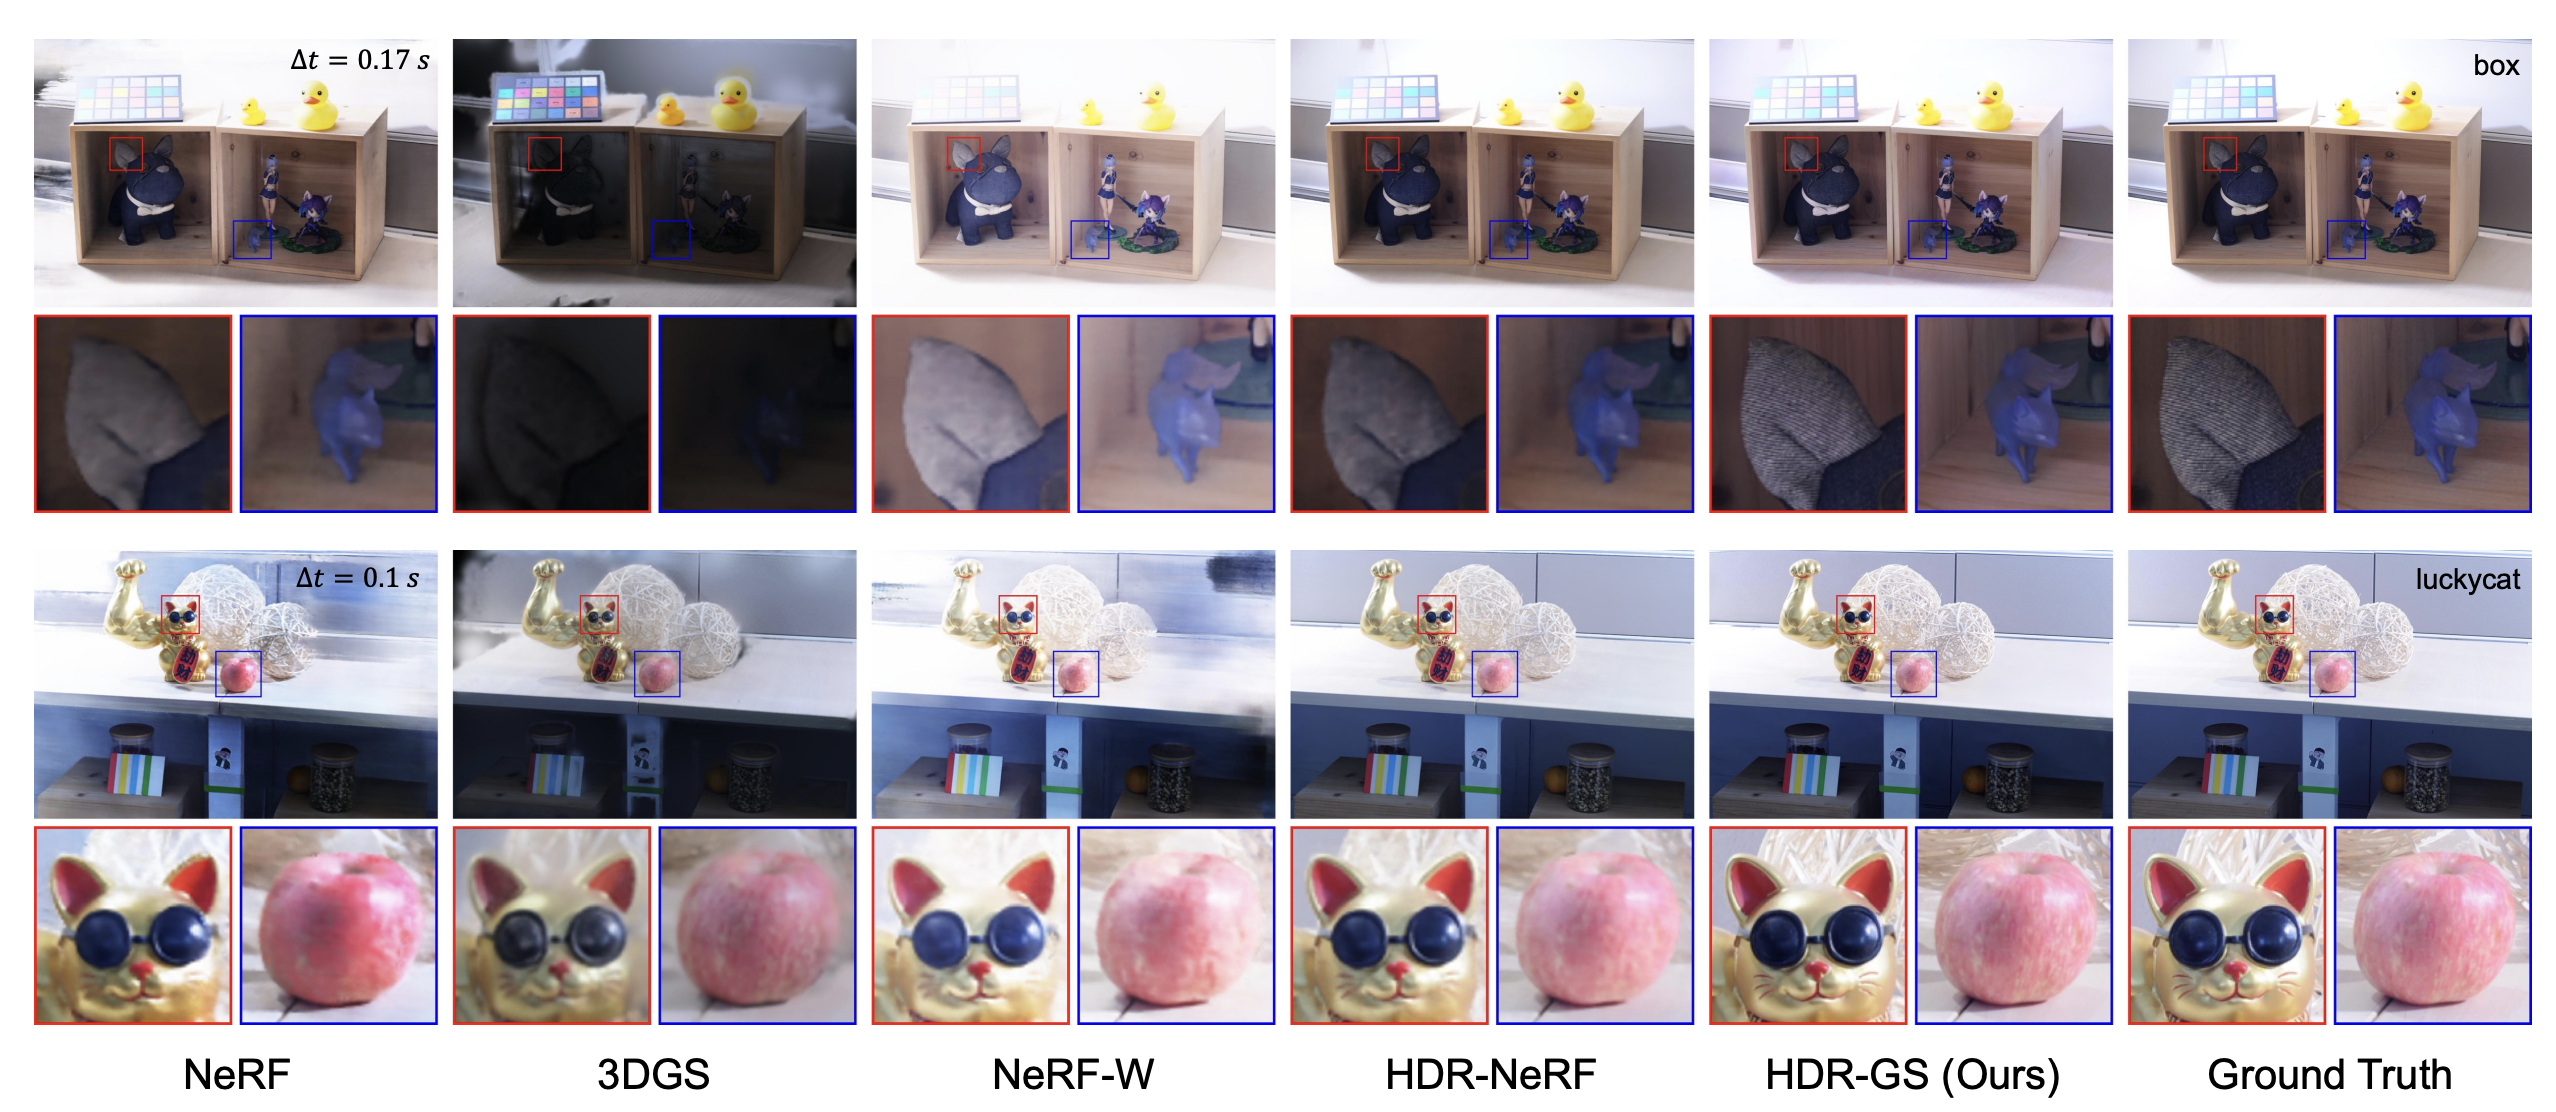
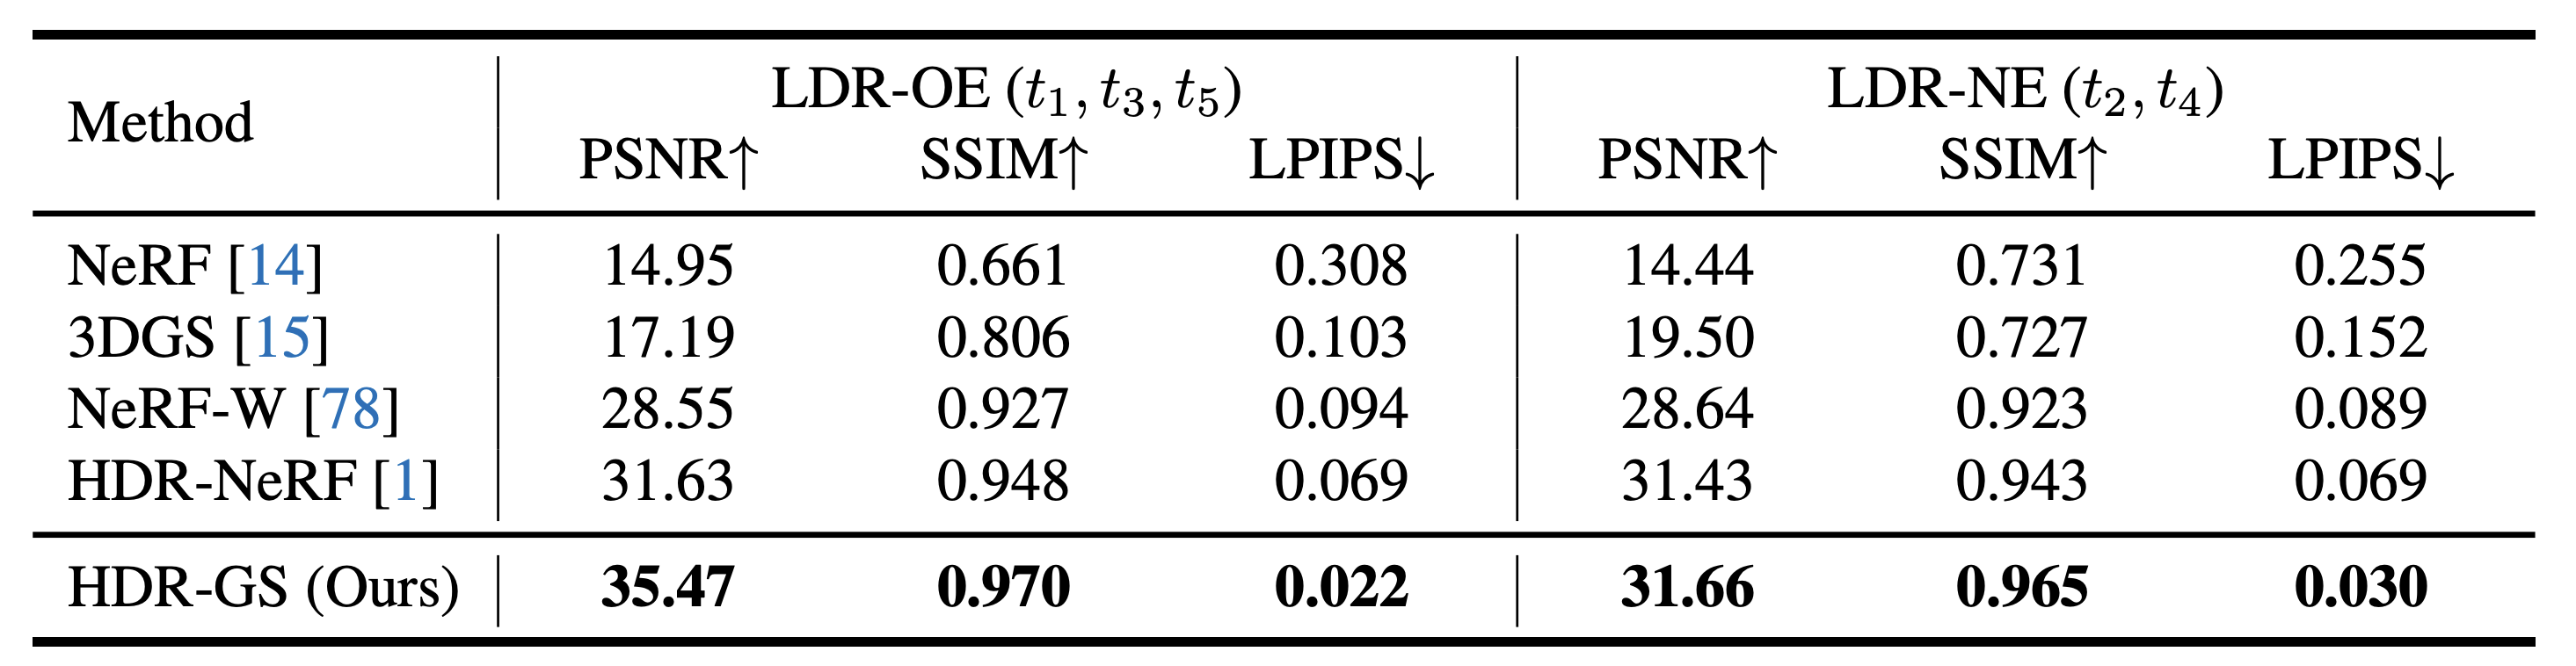
Figures are reproduced from the official project and report the original experiments.
Interactive comparisons: Bathroom · Chair · Diningroom · Dog · Sofa · Sponza
@inproceedings{hdr_gs,
  title={HDR-GS: Efficient High Dynamic Range Novel View Synthesis at 1000x Speed via Gaussian Splatting},
  author={Yuanhao Cai and Zihao Xiao and Yixun Liang and Minghan Qin and Yulun Zhang and Xiaokang Yang and Yaoyao Liu and Alan Yuille},
  booktitle={NeurIPS},
  year={2024}
}