| --- |
| license: mit |
| task_categories: |
| - time-series-forecasting |
| tags: |
| - driving |
| - ADAS |
| - takeover |
| - car-following |
| pretty_name: ADAS-TO longitudinal closing case-control windows |
| --- |
| |
| # ADAS-TO longitudinal — closing case-control windows (n = 5090) |
|
|
| Companion subset of the ADAS-TO dataset for longitudinal (car-following) |
| take-over modeling. **This is a case-control set, not 5090 |
| takeovers**: 2293 takeover cases (arm `T`) and 2797 non-takeover closing |
| controls (arm `Q`) drawn from the same drives. |
|
|
| ## Examples |
|
|
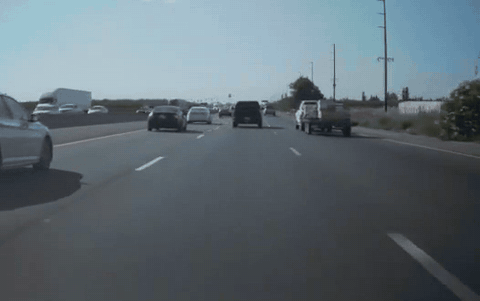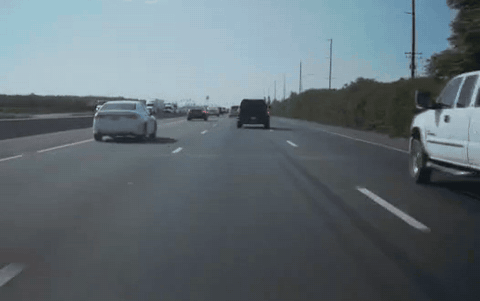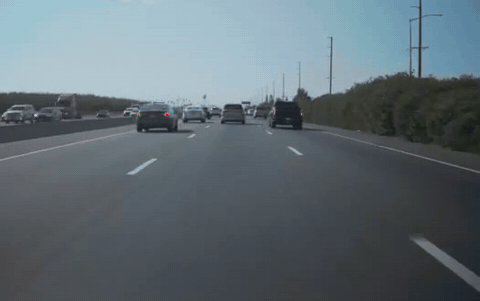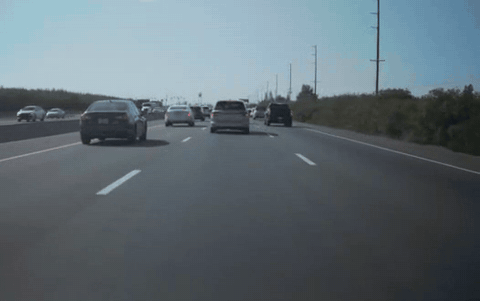
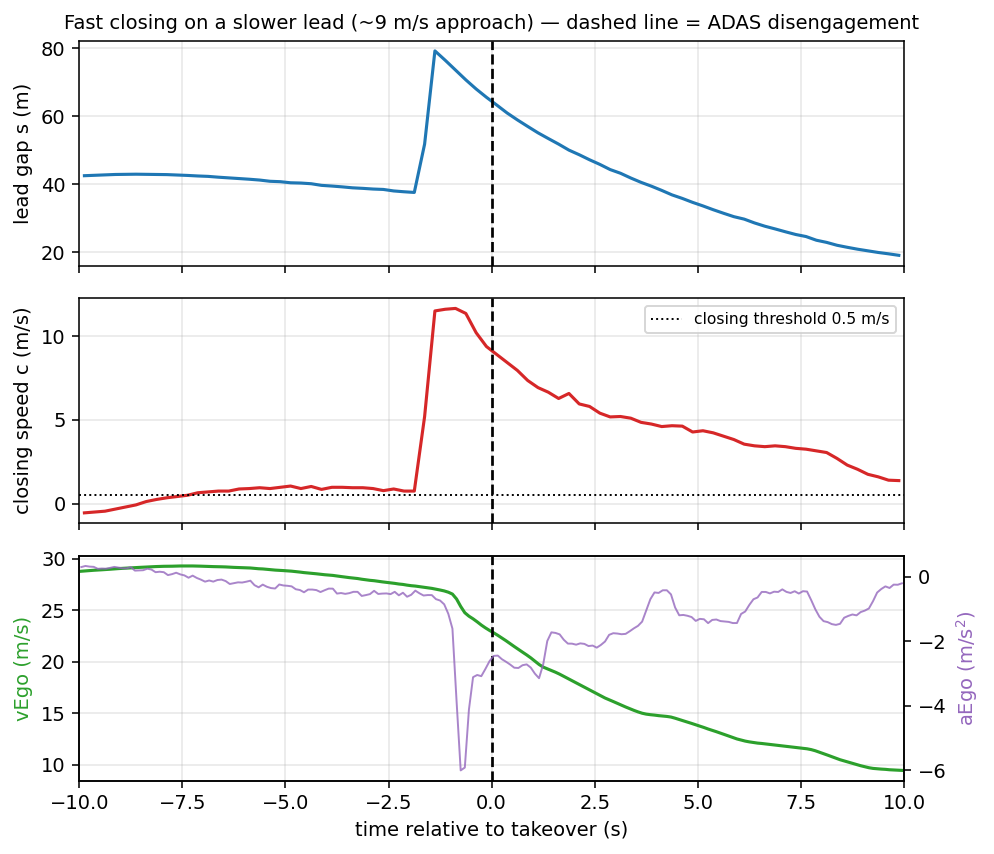
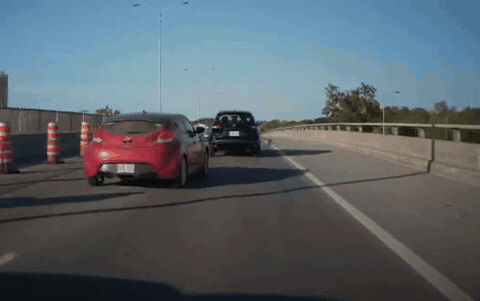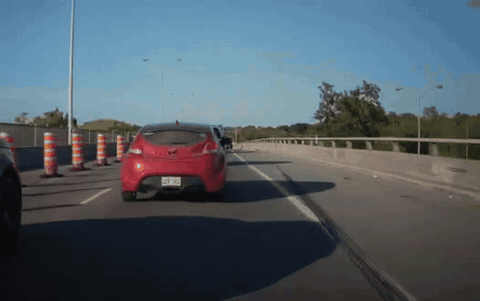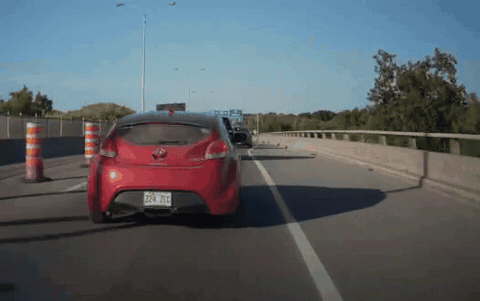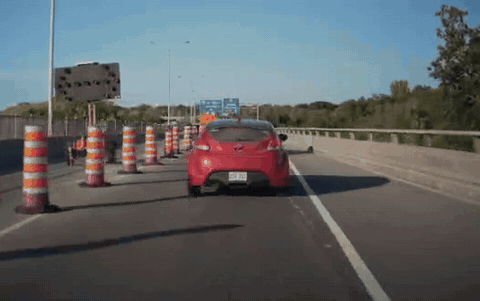
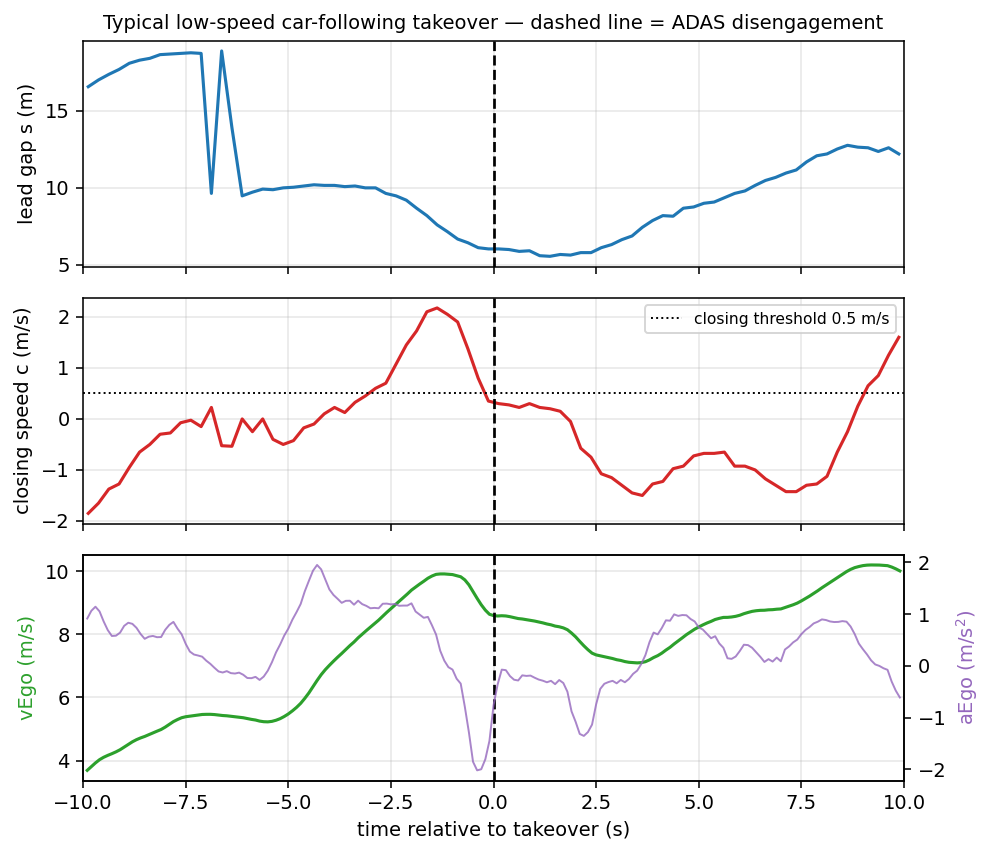
| Forward video (red flash = ADAS disengagement, takeover at 10 s) with the |
| synchronized radar/CAN signals of the same clip. |
|
|
| **Fast closing on a slower lead (~9 m/s approach)** — `TOYOTA_PRIUS/driver_142/route_001/0` |
|
|
|  |
|
|
|  |
|
|
| **Typical low-speed car-following takeover** — `TOYOTA_PRIUS/driver_182/route_010/2` |
|
|
|  |
|
|
|  |
|
|
| **Closing resolved to standstill** — `VOLKSWAGEN_SHARAN_MK2/driver_289/route_007/1` |
|
|
| 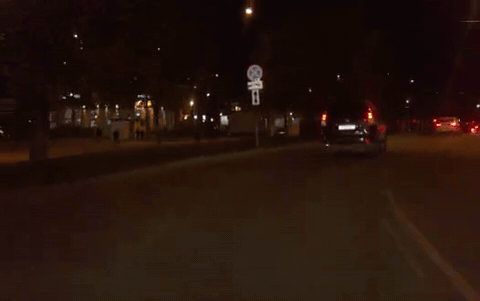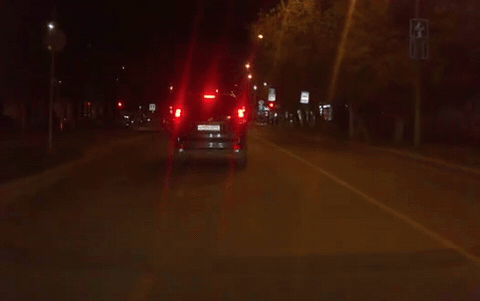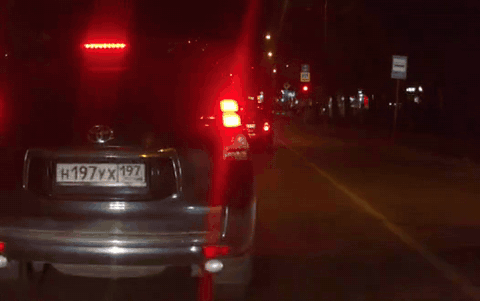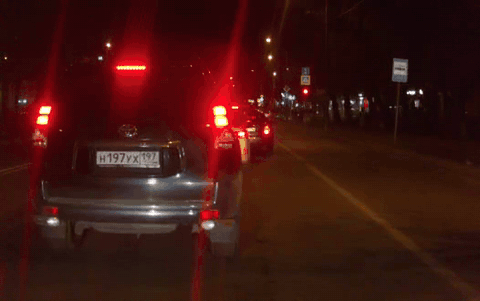 |
|
|
| 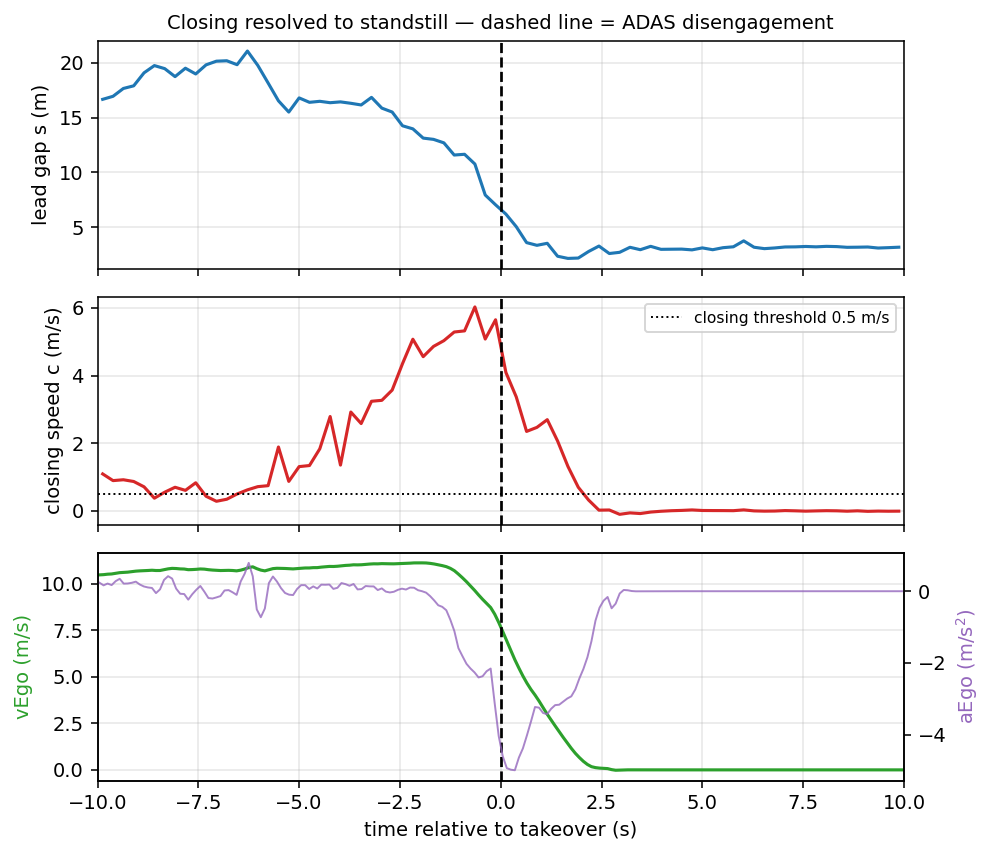 |
|
|
| **Case vs same-drive matched control** — both contain sustained closing; |
| only the case ends in a takeover: |
|
|
| 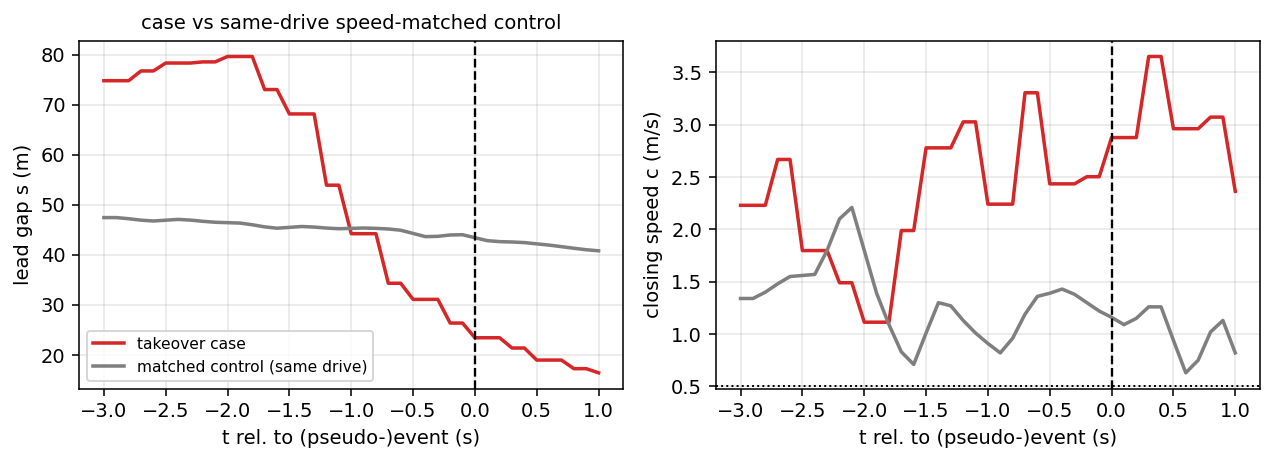 |
|
|
| ## Windows (`windows.parquet`) |
|
|
| Per window: 41 samples at 10 Hz, `t` in [-3.0, +1.0] s; `t = 0` is the |
| ADAS disengagement (cases) or the pseudo-event anchor (controls). |
|
|
| | column | description | |
| |---|---| |
| | win_id | window id (`T_*` case / `Q_*` control) | |
| | t | time relative to (pseudo-)event, s | |
| | s | radar lead gap, m (NaN when no valid lead) | |
| | vr | radar relative speed `vRel`, m/s (closing speed = `-vr`) | |
| | vE | ego speed, m/s | |
| | aE | ego measured acceleration, m/s^2 (realized vehicle response) | |
| | valid | lead-valid flag (`isfinite(s) & s > 0.5`) | |
|
|
| ## Meta (`meta.parquet`) |
|
|
| `arm` (T/Q), anonymized `clip` (cases; matches the public ADAS-TO release |
| paths), `car_model`, anonymized `driver`/`route`, window mean ego speed |
| `v_mean`, sustained-closing duration `sus` (s), `maxDv`/`minTTC` over the |
| pre-event closing window, control sub-window offset `t0_sub`, and the |
| case-control pairing (`has_ctrl`, `matched_case`, `match_relaxed`). |
|
|
| ## Clips (`clips/`) |
|
|
| For each case (arm `T`) the original 20 s clip is included at |
| `clips/{meta.clip}/`: the forward video `takeover.mp4` (takeover at |
| 10 s) and 13 openpilot log CSVs (carState, carControl, carOutput, |
| controlsState, drivingModelData, longitudinalPlan, radarState, |
| accelerometer, VehicleIMU, Gyroscope, CameraOdometry, LiveCalibration, |
| LiveParameters) plus a sanitized `meta.json` (anonymized driver/route |
| ids). File layout and anonymization follow the main ADAS-TO release. |
| Controls (arm `Q`) have no clips by construction — they are unlabeled |
| engaged stretches of the same drives; their radar/ego series are in |
| `windows.parquet`. |
|
|
| ## Construction |
|
|
| - Cases: all-corpus longitudinal takeovers with radar lead coverage >= 0.9 |
| over video [7, 11] s and a sustained closing episode (approach speed |
| >= 0.5 m/s for >= 1.0 s) inside [7, 10] s (takeover at 10 s). |
| - Controls: same-drive engaged windows with no driver input and no |
| disengagement, >= 60 s away from every takeover on the route, containing |
| a closing episode under the identical criterion; pseudo-event = episode |
| sub-window start + 3 s; speed-matched (+-5 m/s) per case, K = 2. |
| - 1,436 cases have same-drive matched controls; 857 have none (kept). |
|
|
| ## Caveats |
|
|
| - Case-control sampling: model outputs on this set are not absolute |
| naturalistic takeover probabilities. |
| - `aE` after driver input may reflect the driver, not the automation. |
| - Radar-missed leads and cut-ins are out of scope by construction. |
|
|

