| --- |
| pretty_name: WorldAuditBench |
| task_categories: |
| - other |
| language: |
| - en |
| size_categories: |
| - n<1K |
| tags: |
| - worldauditbench |
| - 3d |
| - simulation |
| - benchmark |
| - multimodal |
| configs: |
| - config_name: default |
| data_files: |
| - split: test |
| path: dataset/tasks.parquet |
| --- |
| |
| # WorldAuditBench |
|
|
| **Interactive 3D World Auditing with Multimodal Agents** |
|
|
| [](https://arxiv.org/pdf/2609.40325) [](https://github.com/UCSB-NLP-Chang/WorldAuditBench) [](https://ucsb-nlp-chang.github.io/WorldAuditBench/) [](https://huggingface.co/spaces/ziyjiang/WorldAuditBench) |
|
|
| 213 tasks · 13 environments · 5 anomaly families |
| UC Santa Barbara · MIT CSAIL · MIT–IBM Watson AI Lab |
|
|
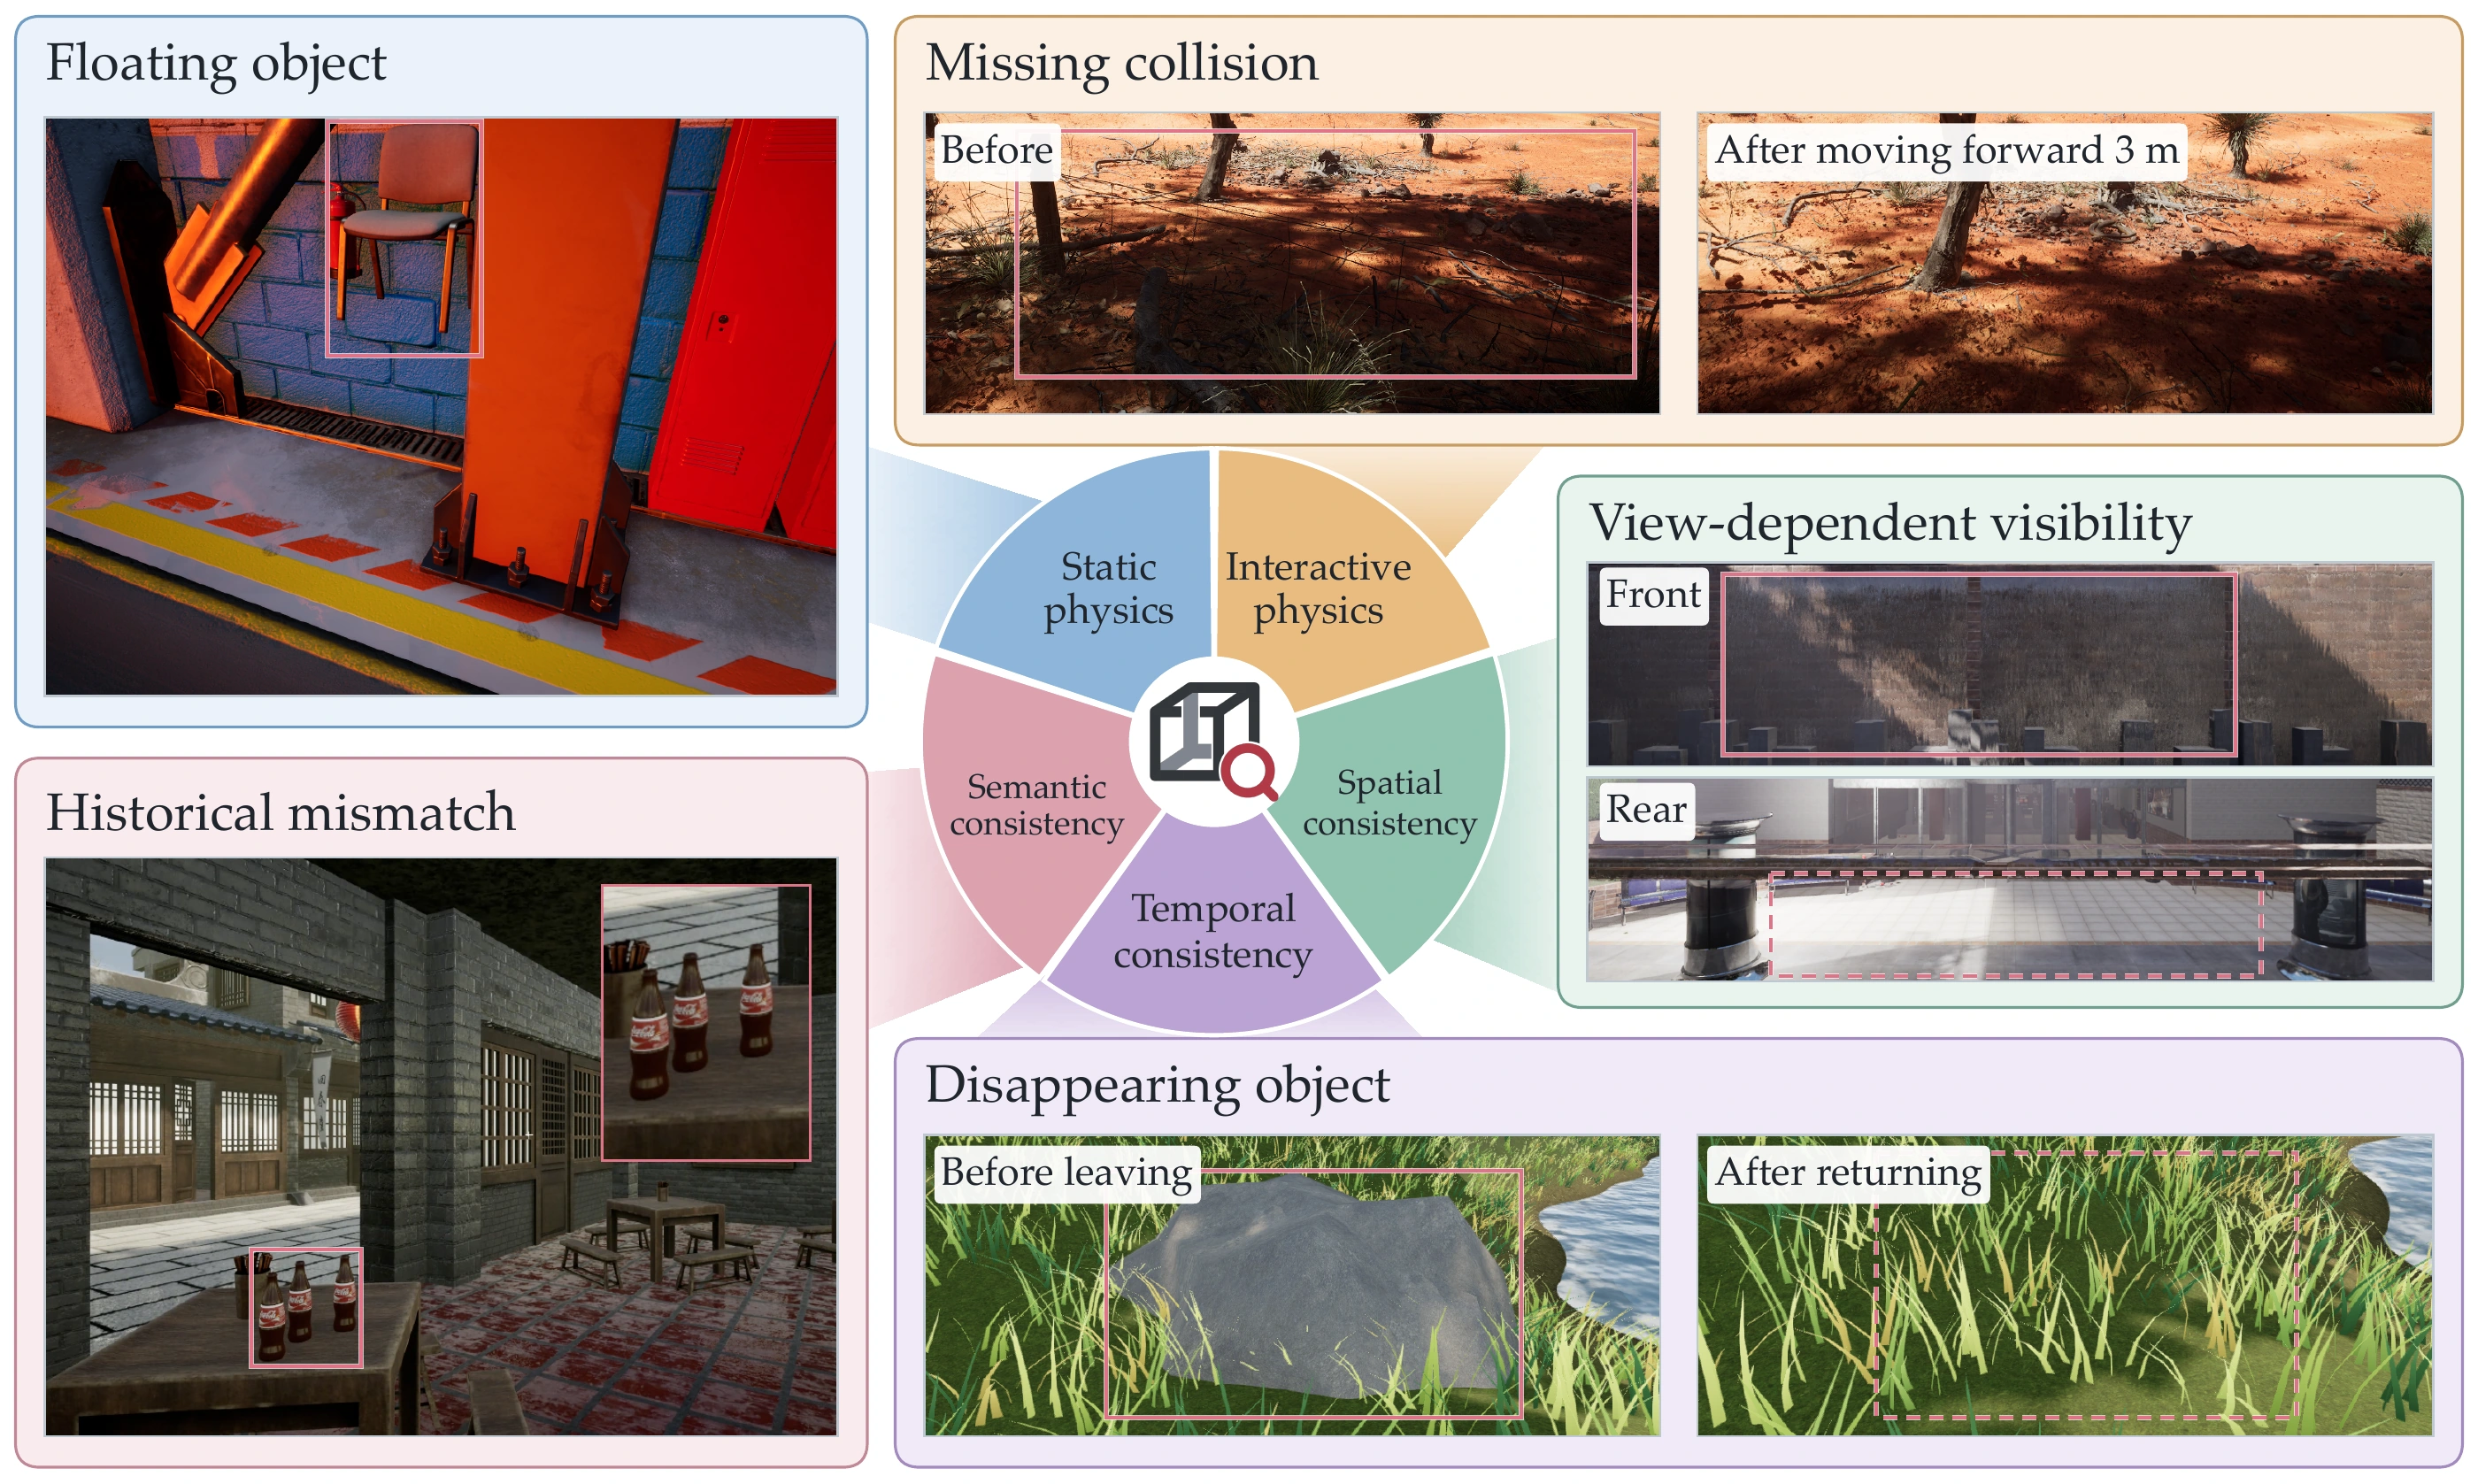
| WorldAuditBench evaluates whether multimodal agents can **explore a 3D world, investigate suspicious observations, and identify anomalies with visual evidence**. An agent may need to approach an object, test a collision, change its viewpoint, or revisit a location to establish what is wrong. |
|
|
|  |
|
|
| *Representative examples from the paper: static physics, interactive physics, spatial consistency, temporal consistency, and semantic consistency.* |
|
|
| ## The benchmark |
|
|
| The evaluation set spans **126 Unreal Engine tasks** and **87 Three.js tasks**, covering furnished interiors, urban scenes and natural environments. |
|
|
| | Anomaly family | What agents investigate | Tasks | |
| | --- | --- | ---: | |
| | Static physics | Floating objects, intersections and implausible scale | 59 | |
| | Interactive physics | Missing collisions, unexpected obstacles and abnormal trajectories | 41 | |
| | Spatial consistency | Visibility, viewpoint, lighting and material inconsistencies | 51 | |
| | Temporal consistency | Changes in existence, attributes or operational state | 40 | |
| | Semantic consistency | Improper configurations and historical incompatibilities | 22 | |
| | **Total** | **15 anomaly types across 13 environments** | **213** | |
|
|
| **Unreal:** Ancient City, Indoor, Industrial, Medieval Village, Rural Australia, Subway and Urban. |
|
|
| **Three.js:** Airfield, Cottage, House, Reef, Sponza and Wilderness. |
|
|
| ## Data |
|
|
| **One task per row.** [`dataset/tasks.parquet`](https://huggingface.co/datasets/ziyjiang/WorldAuditBench/tree/main/dataset) contains all 213 tasks, including inputs, categories, rubrics and maps. |
|
|
| | Field | Contents | |
| | --- | --- | |
| | `task_id`, `engine`, `environment` | Task and environment identifiers | |
| | `category`, `subcategory` | Anomaly family and type | |
| | `input` | Instruction and scene description | |
| | `rubric` | `anomaly`: anomaly description; `expected`: expected behavior | |
| | `map` | Map path or scene URL | |
|
|
| [In-context examples](https://huggingface.co/datasets/ziyjiang/WorldAuditBench/tree/main/examples) are grouped by subcategory. |
|
|
| ```python |
| from datasets import load_dataset |
| |
| benchmark = load_dataset("ziyjiang/WorldAuditBench", split="test") |
| task = benchmark[0] |
| print(task["task_id"], task["input"]) |
| ``` |
|
|
| ## Auditing paradigms |
|
|
|  |
|
|
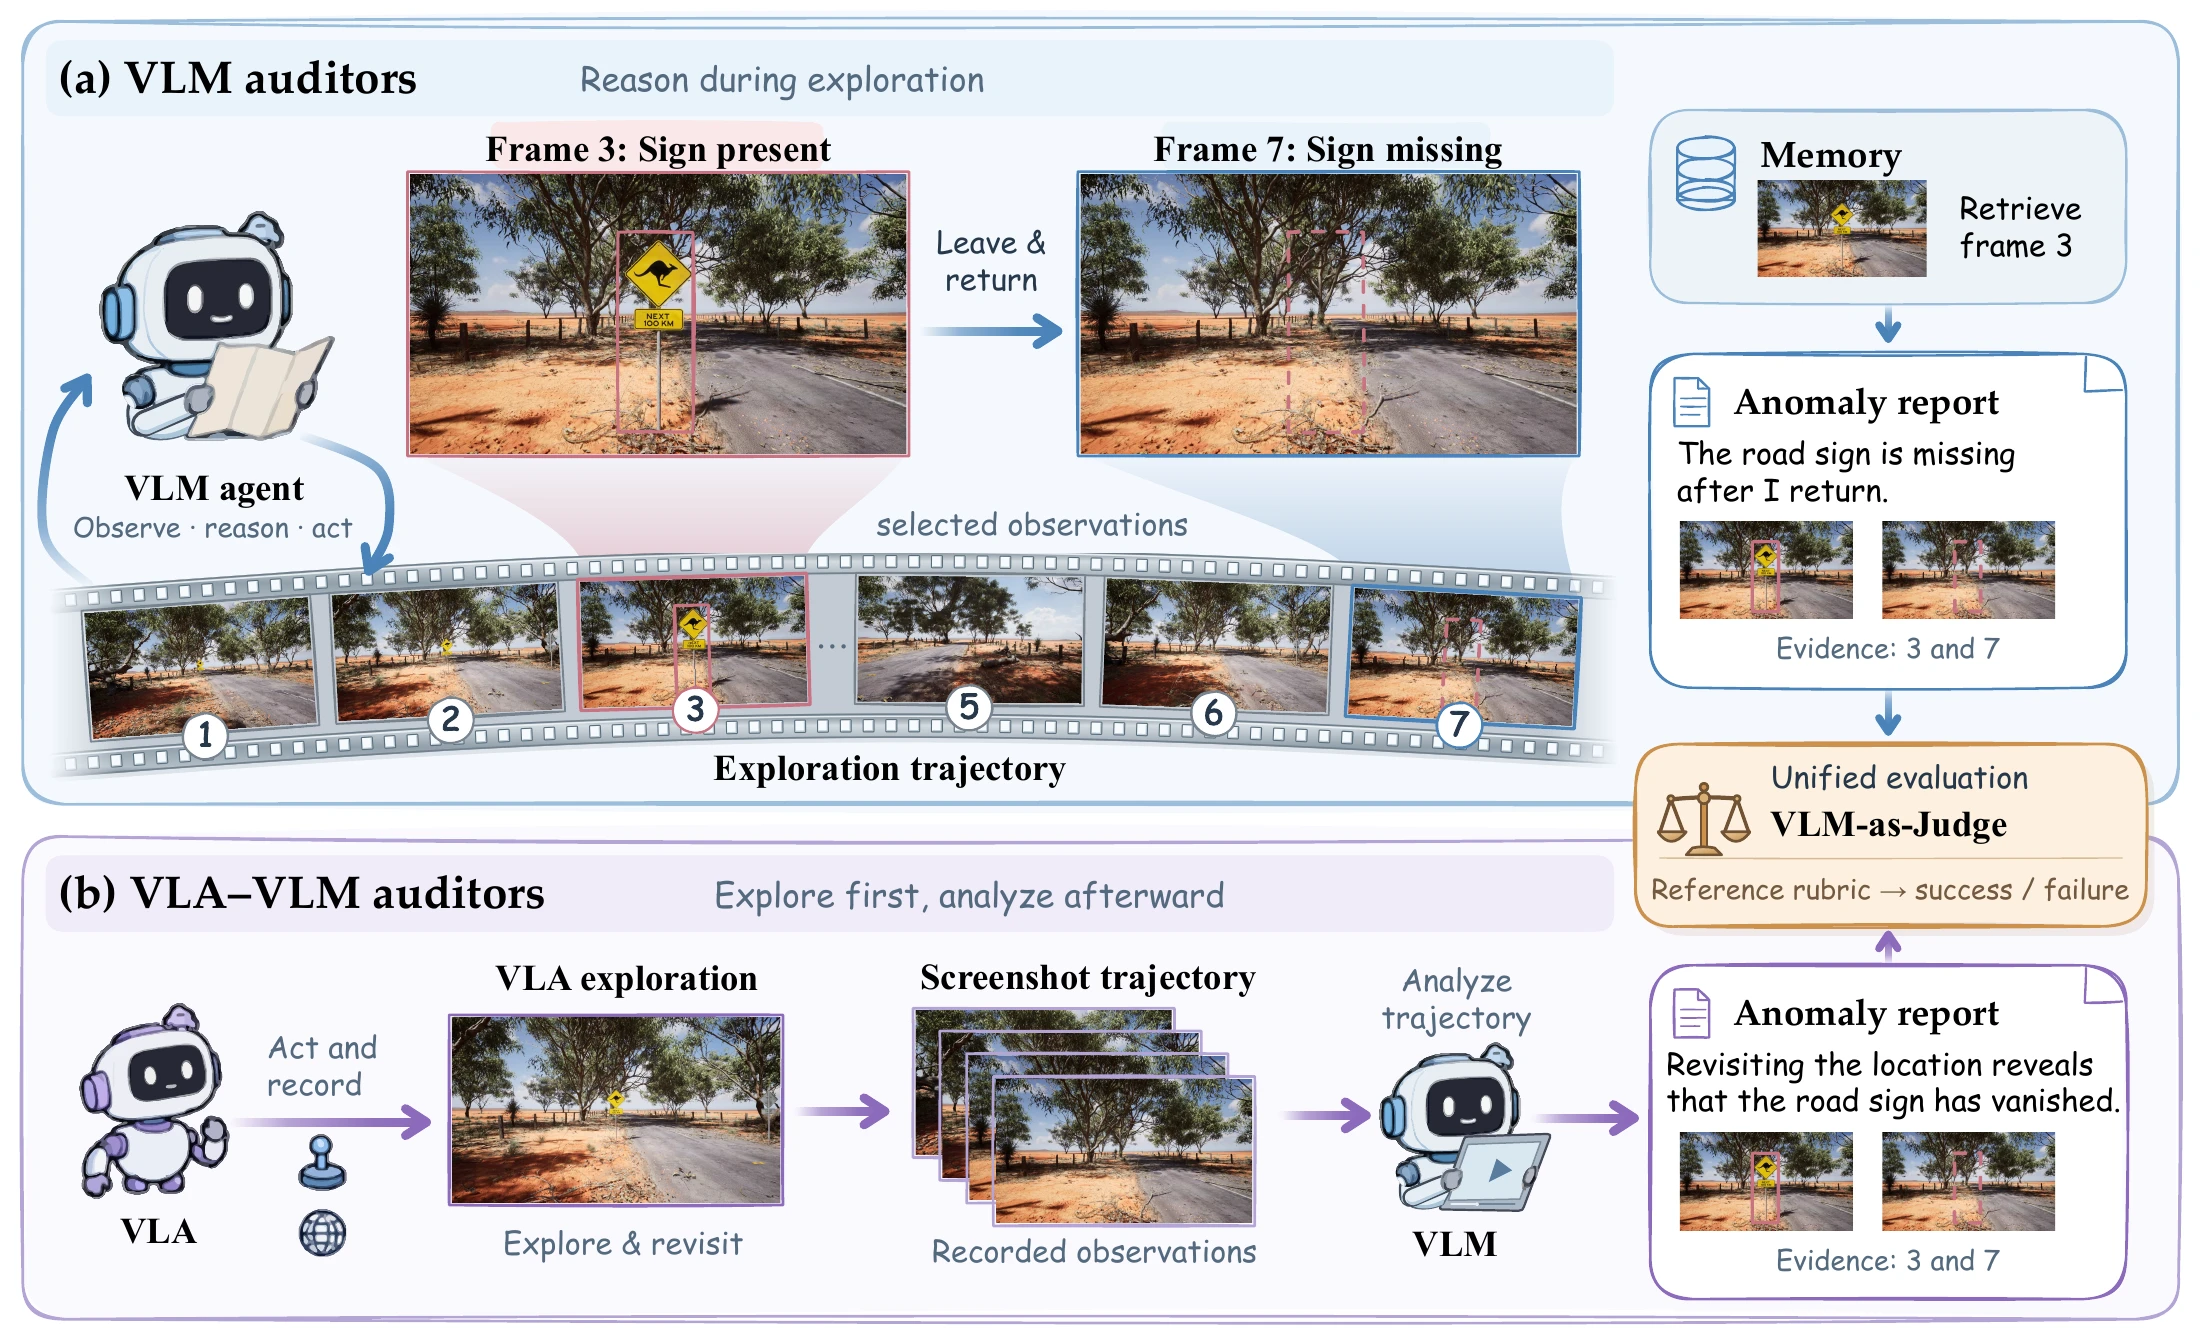
| **VLM agents** reason during exploration and choose their next actions from observations and evidence, with a budget of 40 actions. **VLA + VLM** separates exploration from analysis: a VLA explores for 60 simulated seconds, then a VLM examines the recorded trajectory. |
|
|
| The strongest evaluated agent reaches **42.3%** success, compared with **83.4%** for humans. |
|
|
| ## Citation |
|
|
| ```bibtex |
| @article{jiang2026worldauditbench, |
| title={WorldAuditBench: Interactive 3D World Auditing with Multimodal Agents}, |
| author={Jiang, Ziyan and Yang, Jingbo and Ji, Jiabao and Liu, Yujian and Wu, Qiucheng and Jaakkola, Tommi and Zhang, Yang and Chang, Shiyu}, |
| journal={arXiv preprint arXiv:2609.40325}, |
| year={2026} |
| } |
| ``` |
|
|

