| --- |
| pipeline_tag: feature-matching |
| library_name: pytorch |
| license: apache-2.0 |
| tags: |
| - transformer |
| - feature-matching |
| - accv-2022 |
| - vision |
| - scannet |
| - megadepth |
| datasets: |
| - scannet |
| - megadepth |
| --- |
| |
| # MatchFormer: Interleaving Attention in Transformers for Feature Matching (ACCV 2022) |
|
|
| Official model checkpoints for **MatchFormer: Interleaving Attention in Transformers for Feature Matching** (ACCV 2022 Oral). |
|
|
| <div align="center"> |
|
|
| [](https://arxiv.org/abs/2203.09645) |
| [](https://github.com/InSAI-Lab/MatchFormer) |
| [](https://huggingface.co/collections/InSAI-Lab) |
|
|
| </div> |
|
|
| --- |
|
|
| ## 📌 Introduction |
|
|
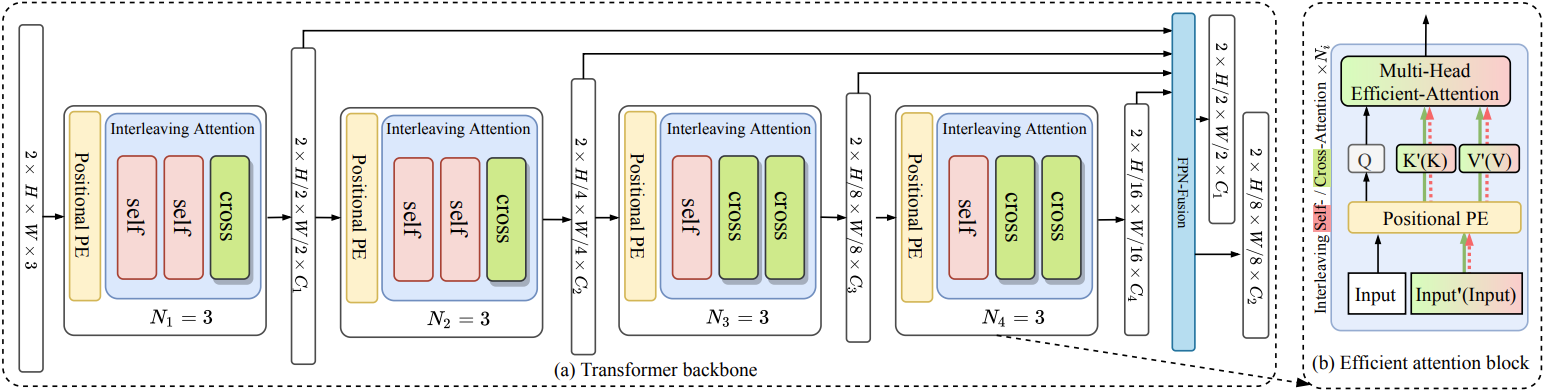
| In this work, we propose a novel hierarchical extract-and-match transformer, termed **MatchFormer**. Inside each stage of the hierarchical encoder, we interleave self-attention for feature extraction and cross-attention for feature matching, enabling an intuitive and powerful **extract-and-match** scheme. MatchFormer establishes robust and accurate dense correspondences across diverse indoor and outdoor challenging scenes. |
|
|
|  |
|
|
| --- |
|
|
| ## 📂 Model Zoo & File Structure |
|
|
| ```text |
| InSAI-Lab/MatchFormer |
| ├── indoor-large-SEA.ckpt # Indoor large model with SEA (Spatial-Entropy Attention) (89.5 MB) |
| ├── indoor-lite-LA.ckpt # Indoor lightweight model with LA (Linear Attention) (77.4 MB) |
| ├── outdoor-large-LA.ckpt # Outdoor large model with LA (77.4 MB) |
| └── outdoor-lite-SEA.ckpt # Outdoor lightweight model with SEA (103.5 MB) |
| ``` |
|
|
| --- |
|
|
| ## 📊 Benchmark Results |
|
|
| ### 1. Indoor Relative Pose Estimation on ScanNet (AUC) |
|
|
| | Model | Backbone | Resolution | AUC @ 5° | AUC @ 10° | AUC @ 20° | Weights | |
| | :--- | :--- | :---: | :---: | :---: | :---: | :--- | |
| | **MatchFormer-Large** | largesea | (8, 2) | **43.3** | **63.4** | **77.1** | [`indoor-large-SEA.ckpt`](https://huggingface.co/InSAI-Lab/MatchFormer/resolve/main/indoor-large-SEA.ckpt) | |
| | **MatchFormer-Lite** | litela | (8, 4) | **38.8** | **59.2** | **74.0** | [`indoor-lite-LA.ckpt`](https://huggingface.co/InSAI-Lab/MatchFormer/resolve/main/indoor-lite-LA.ckpt) | |
|
|
| ### 2. Outdoor Relative Pose Estimation on MegaDepth (AUC) |
|
|
| | Model | Backbone | Resolution | AUC @ 5° | AUC @ 10° | AUC @ 20° | Weights | |
| | :--- | :--- | :---: | :---: | :---: | :---: | :--- | |
| | **MatchFormer-Large** | largela | (8, 2) | **53.3** | **69.7** | **81.8** | [`outdoor-large-LA.ckpt`](https://huggingface.co/InSAI-Lab/MatchFormer/resolve/main/outdoor-large-LA.ckpt) | |
| | **MatchFormer-Lite** | litesea | (8, 4) | **48.2** | **65.1** | **78.4** | [`outdoor-lite-SEA.ckpt`](https://huggingface.co/InSAI-Lab/MatchFormer/resolve/main/outdoor-lite-SEA.ckpt) | |
|
|
| --- |
|
|
| ## ⚡ Quick Download Guide |
|
|
| ### Option 1: Hugging Face CLI |
|
|
| ```bash |
| # Download all MatchFormer weights to model/weights/ |
| hf download InSAI-Lab/MatchFormer --local-dir model/weights |
| |
| # Or download a specific checkpoint |
| hf download InSAI-Lab/MatchFormer indoor-large-SEA.ckpt --local-dir model/weights |
| ``` |
|
|
| ### Option 2: Python `huggingface_hub` |
| |
| ```python |
| from huggingface_hub import hf_hub_download |
|
|
| # Download indoor large SEA checkpoint |
| ckpt_path = hf_hub_download( |
| repo_id="InSAI-Lab/MatchFormer", |
| filename="indoor-large-SEA.ckpt", |
| local_dir="model/weights" |
| ) |
| ``` |
| |
| --- |
|
|
| ## 📖 Citation |
|
|
| ```bibtex |
| @inproceedings{wang2022matchformer, |
| title={MatchFormer: Interleaving Attention in Transformers for Feature Matching}, |
| author={Wang, Qing and Zhang, Jiaming and Yang, Kailun and Peng, Kunyu and Stiefelhagen, Rainer}, |
| booktitle={Asian Conference on Computer Vision (ACCV)}, |
| year={2022} |
| } |
| ``` |
|
|


