

DexWeave: Learning Dexterous Humanoid Loco-Manipulation from Human Demonstrations
Paper • 2609.34724 • Published
The dataset viewer is not available because its heuristics could not detect any supported data files. You can try uploading some data files, or configuring the data files location manually.
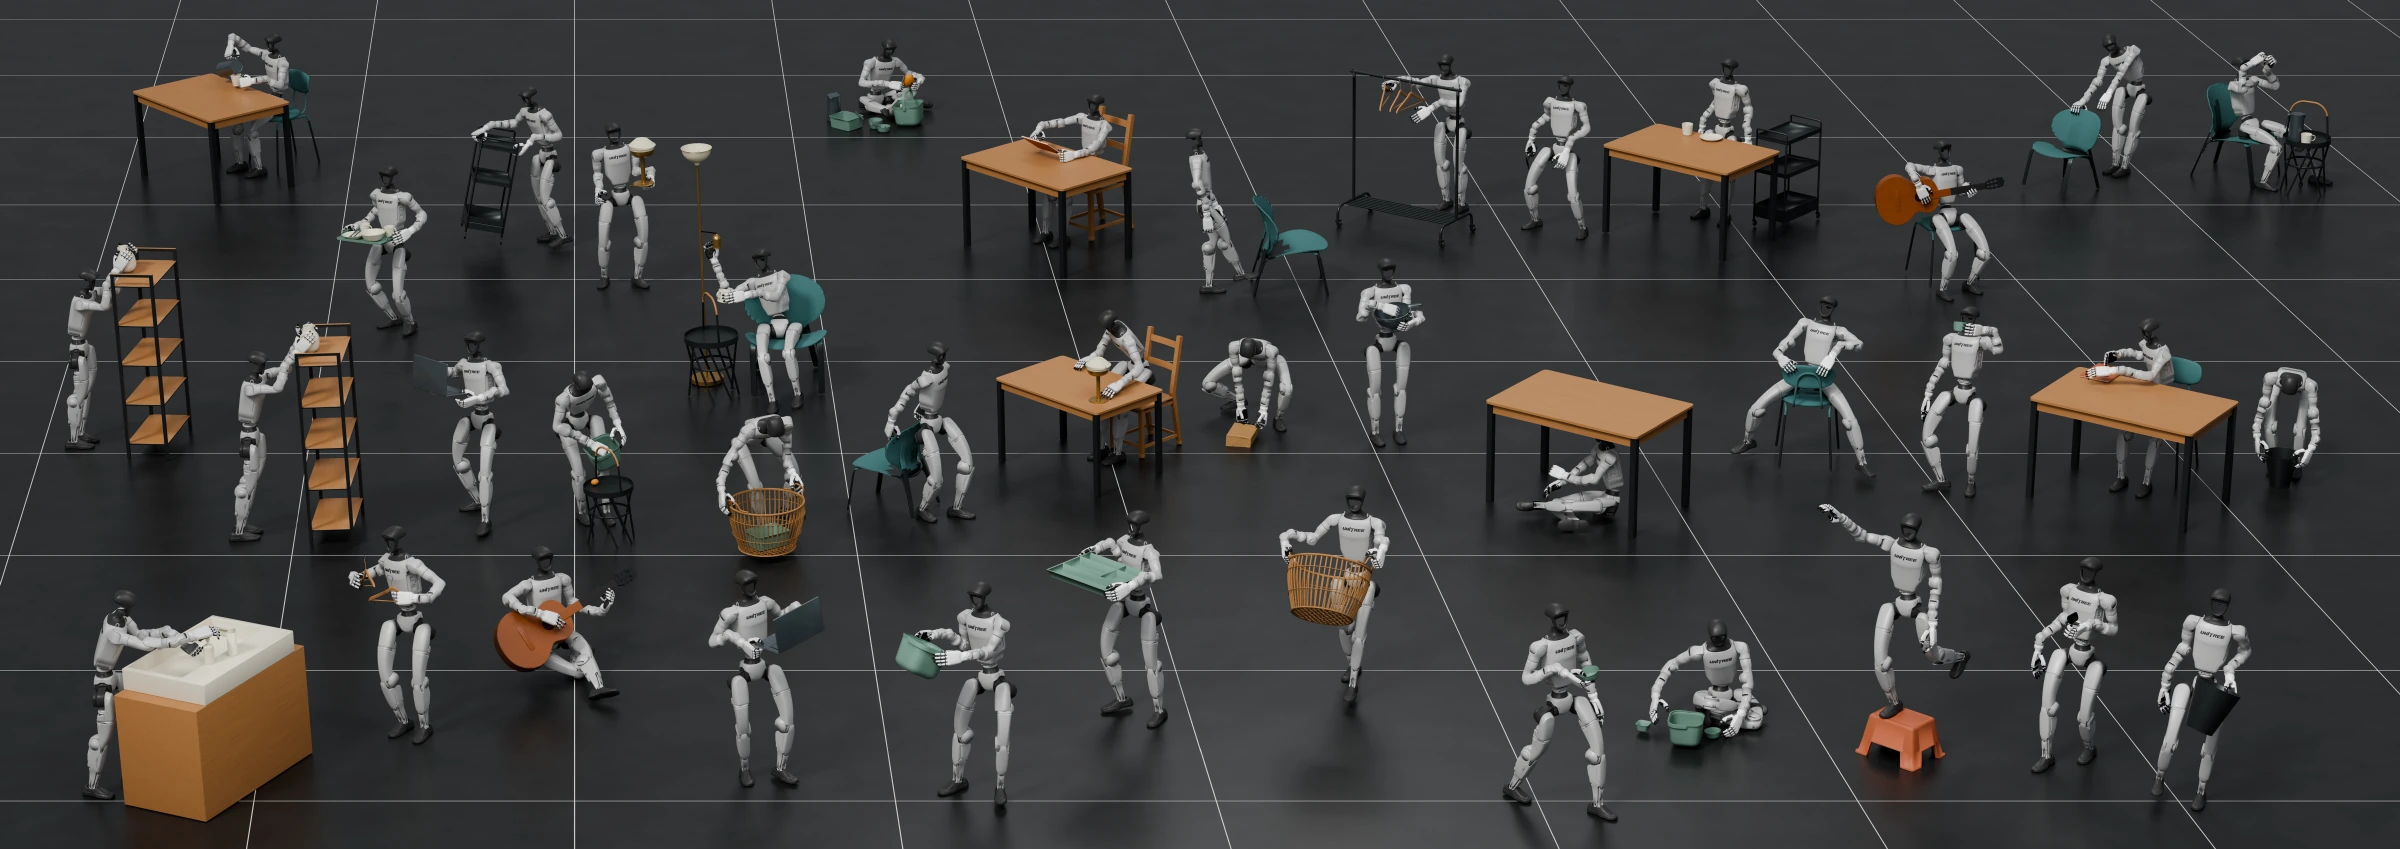
DexWeave studies how to transfer coordinated human body, hand, and object interactions to a dexterous humanoid. It combines interaction-consistent motion retargeting with anatomy-aware whole-body policy learning.
This dataset provides 2,070 retargeted reference sequences derived from HUMOTO and GRAB for Unitree G1 with Inspire RH56DFX hands, together with matching per-frame evaluation data. The references contain robot motion, object trajectories, and interaction annotations.
| Source | Sequences | Frames | Motion NPZ | Evaluation NPZ |
|---|---|---|---|---|
| HUMOTO | 735 | 390,988 | 735 | 735 |
| GRAB | 1,335 | 676,647 | 1,335 | 1,335 |
| Total | 2,070 | 1,067,635 | 2,070 | 2,070 |
All sequences are exported at 50 Hz (dt = 0.02 s). The 4,140 NPZ files occupy approximately 12.9 GB.
The target robot has 29 independent body joints and 12 independent hand joints. The saved trajectories contain 53 joint coordinates, including 12 coupled joints. Use joint_names to interpret the columns of joint_pos.
These are retargeted motion references rather than policy execution rollouts. The release does not define train, validation, or test splits.
Each sequence has two matching files:
<sequence>_opt.npz: the final robot and scene trajectory, with contact and support information.<sequence>_val.npz: per-frame evaluation data associated with that trajectory, including source-target hand errors and interaction masks. val is not a validation-set split.data/
├── HUMOTO/
│ └── <sequence>/
│ ├── <sequence>_opt.npz
│ └── <sequence>_val.npz
└── GRAB/
└── <subject>/
└── <sequence>/
├── <sequence>_opt.npz
└── <sequence>_val.npz
For GRAB, retain the subject in the sequence identifier, for example s9/wineglass_pass_1.
For motion files, T denotes the sequence length and N the number of scene objects.
| Key | Shape | Description |
|---|---|---|
root_pos |
(T, 3) |
Robot floating-base position in world coordinates |
root_quat |
(T, 4) |
Robot floating-base orientation, wxyz |
joint_pos |
(T, 53) |
Joint positions in the order specified by joint_names |
joint_names |
(53,) |
Joint names corresponding to the saved columns |
object_names |
(N,) |
Scene-object names |
object_pos |
(T, N, 3) |
Object positions in world coordinates |
object_quat |
(T, N, 4) |
Object orientations, wxyz |
object_demo_scale |
(T, N) |
Per-frame object scales |
object_active |
(T, N) |
Object activity masks |
object_mesh_paths |
(N,) |
Object mesh references |
contact_truth_left, contact_truth_right |
(T, N, 5) |
Per-object, per-finger contact annotations |
fps, dt |
Scalars | Export frame rate and time step |
retime_source_indices |
(T,) |
Correspondence to the source motion timeline |
source_dataset, source_seq_name |
String scalars | Source dataset and sequence identifier |
Positions are in meters, joint angles in radians, and quaternions use wxyz order. Robot and object poses share the saved world coordinate frame.
Evaluation files retain the matching sequence identity and time alignment. Their per-frame hand diagnostics include primary-finger position error, secondary-finger position error, palm-normal angular error, and left/right interaction masks.
Additional fields vary across sequences and source datasets; inspect data.files for the complete key list. Mesh references do not embed geometry: robot models and object meshes are not included in this NPZ release.
Download all motion and evaluation files:
python -m pip install -U huggingface_hub numpy
hf download naichuan04/DexWeave --repo-type dataset --local-dir DexWeave
To download one sequence together with its matching evaluation file:
hf download naichuan04/DexWeave --repo-type dataset --local-dir DexWeave \
  --include "data/GRAB/s9/wineglass_pass_1/*"
The download preserves the directory structure. Both motion and evaluation NPZ files are provided here; reading them does not require downloading the original HUMOTO or GRAB human-motion data.
from pathlib import Path
import numpy as np

folder = Path("DexWeave/data/GRAB/s9/wineglass_pass_1")

with np.load(folder / "wineglass_pass_1_opt.npz", allow_pickle=False) as motion:
    print(motion["source_seq_name"].item())       # s9/wineglass_pass_1
    print(motion["joint_pos"].shape)             # (333, 53)
    print(motion["object_pos"].shape)            # (333, 2, 3)
    print(float(motion["fps"]))                 # 50.0

with np.load(folder / "wineglass_pass_1_val.npz", allow_pickle=False) as evaluation:
    print(evaluation.files)
Keep each opt/val pair together when using the saved evaluation data.
If you use these references, please cite DexWeave:
@article{sun2026dexweave,
  author  = {Sun, Naichuan and Shen, Haotian and Zhang, Yizhang and Feng, Luying and Wang, Haoze and Xiangli, Yuanbo and Jin, Yaochu and Liu, Peidong},
  title   = {DexWeave: Learning Dexterous Humanoid Loco-Manipulation from Human Demonstrations},
  journal = {arXiv},
  year    = {2026},
}
Please also acknowledge the source datasets used in your experiments: HUMOTO, GRAB, and ContactDB, which provides object meshes used by GRAB.